Ario Barin Ostovary

Software Engineering, University of Waterloo

Kado Robotics

Cofounder, September 2026 to now.

In September I started Kado with Kevin Dang, another Waterloo student. We're building the workflows that let robot arms assemble and test hardware prototypes, cheaply and without people.

The cell we're working toward, in simulation:

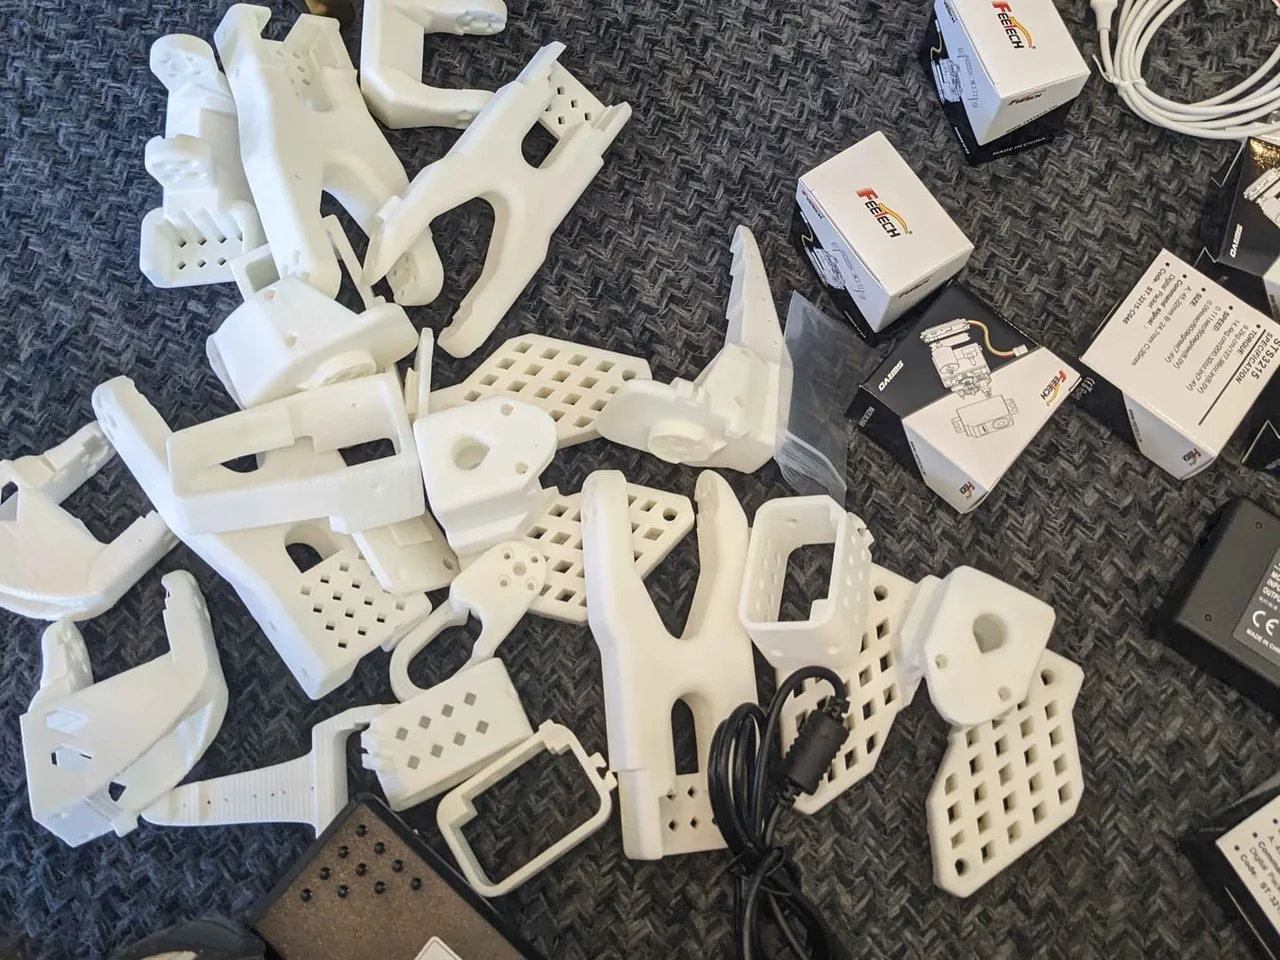
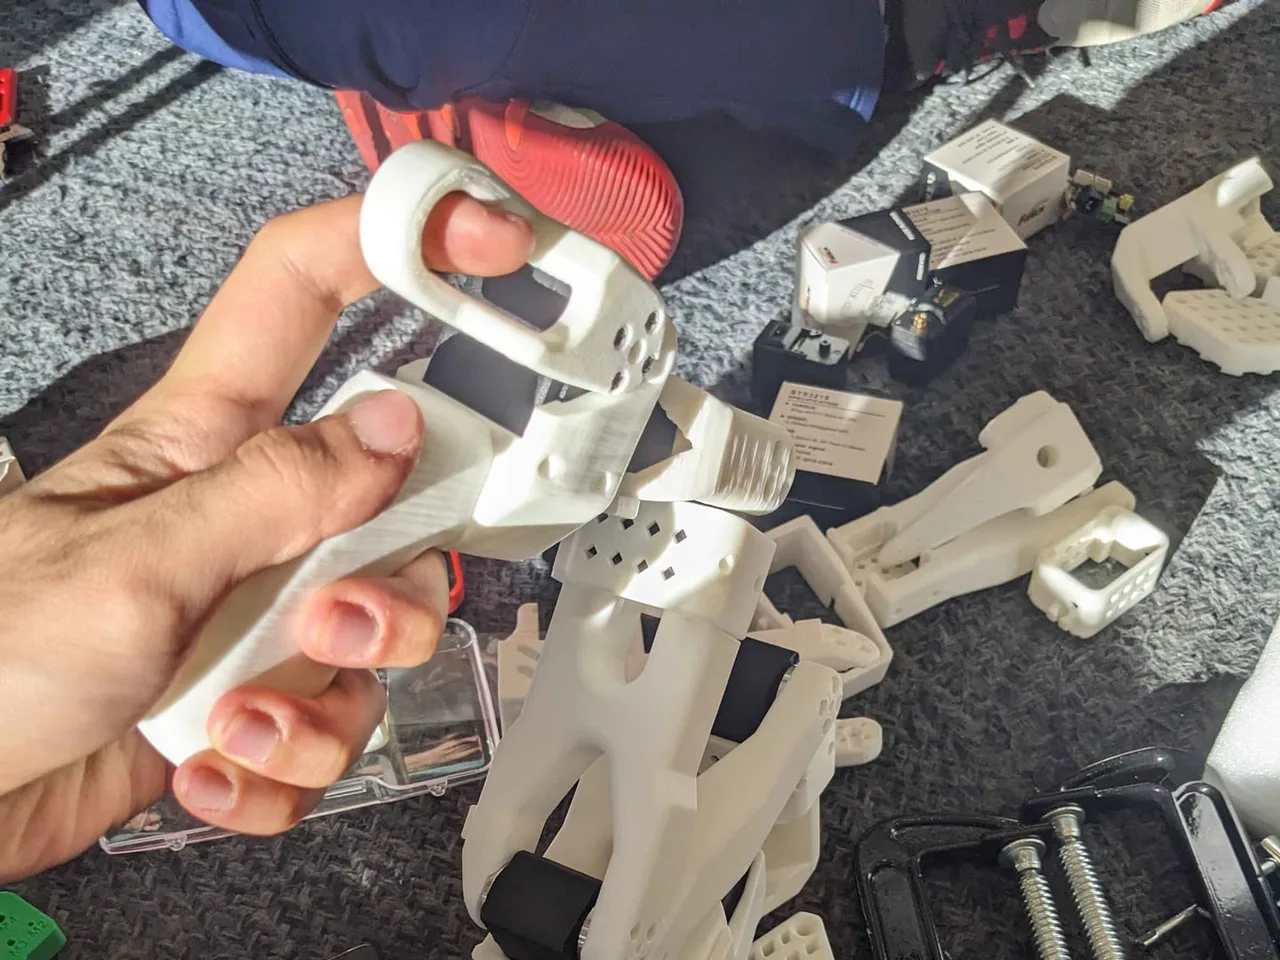
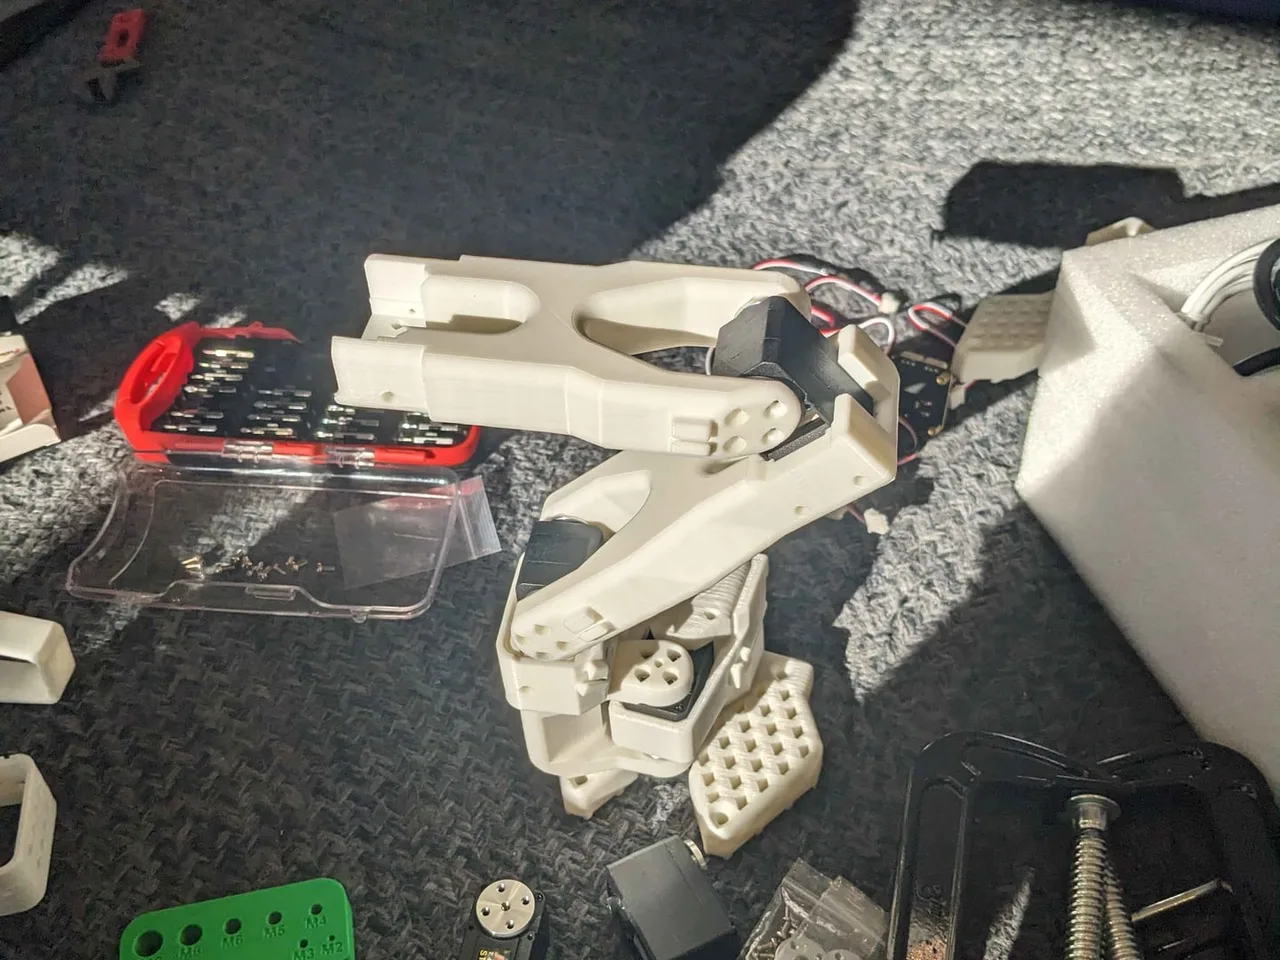
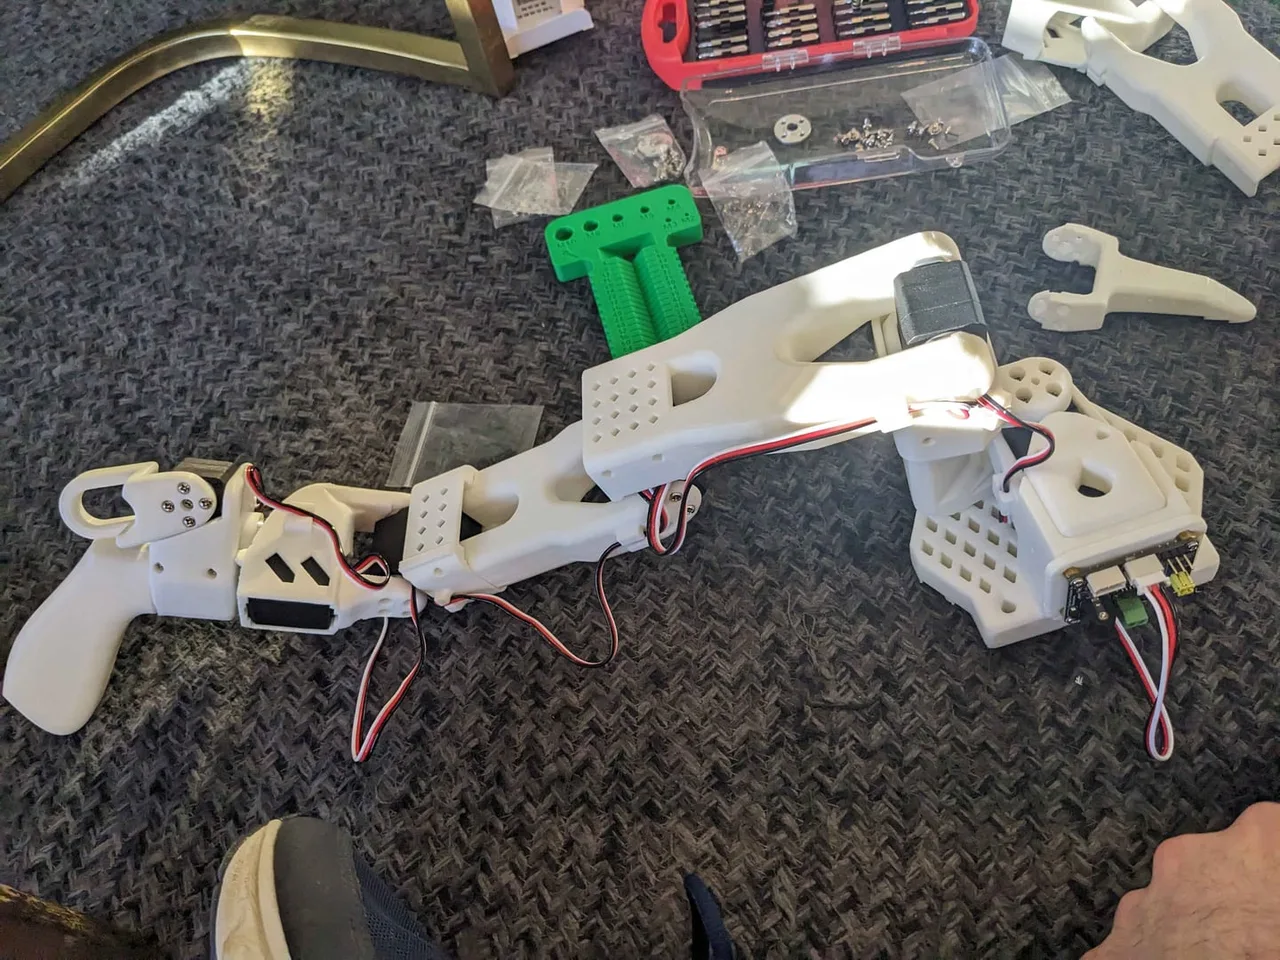
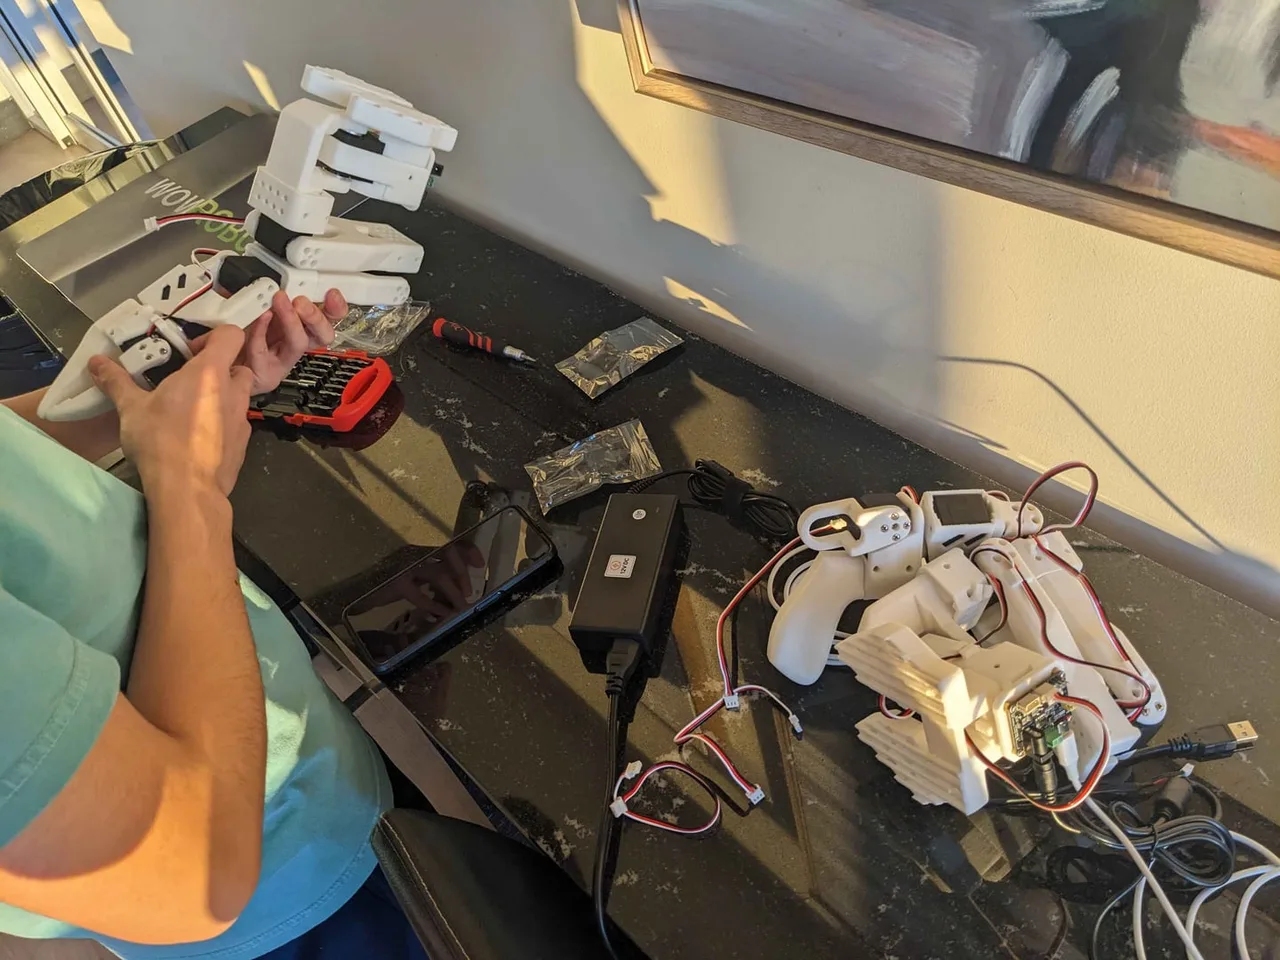
We built the SO-101 arms we won at Hack the North on September 23.
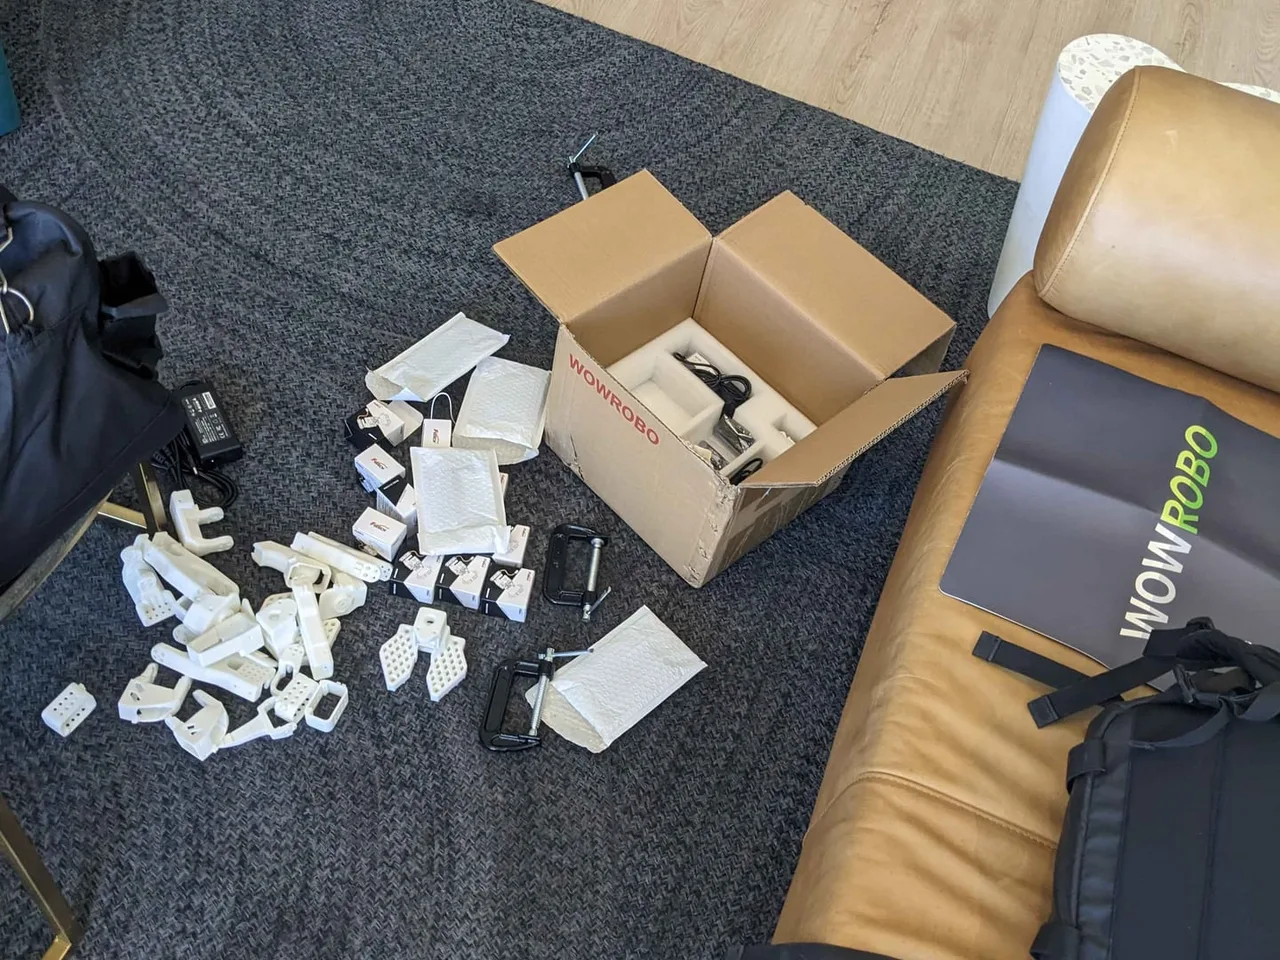
The SO-101 kit unboxed on the floor, printed parts spilling out of the boxWhite printed arm links, servos and power supplies spread across the carpetA half-assembled arm held in hand, with servos fitted into the printed linksA half-built arm on the carpet next to the screwdriver kitThe finished leader and follower arms lying side by sideCalibrating the arms at a desk next to a laptop

I work on the learning side: ACT training and inference on the LeRobot SO-101, with VLAs and world models next.

9 of our 101 duck-to-bowl demonstrations.

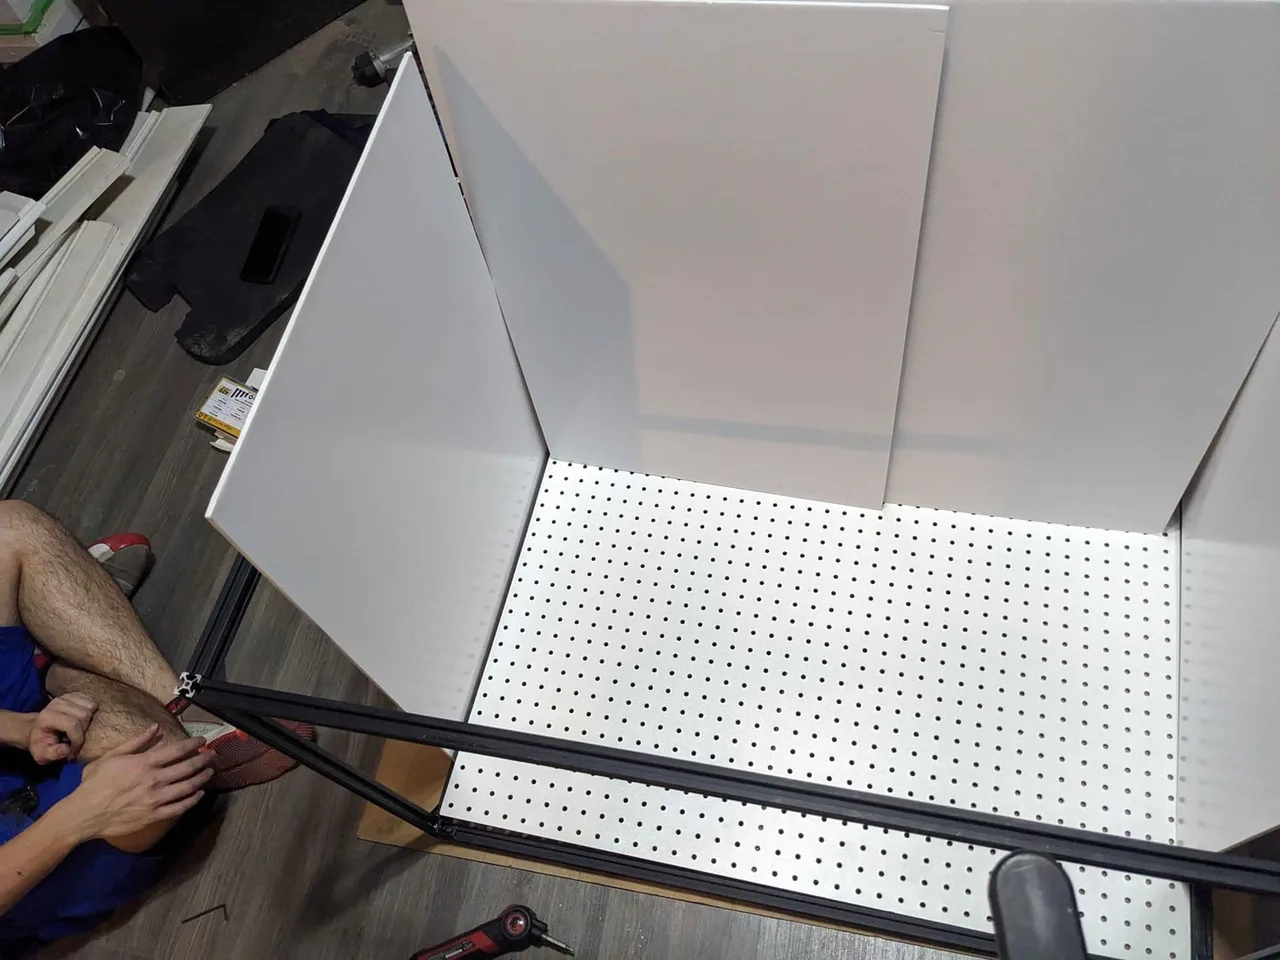
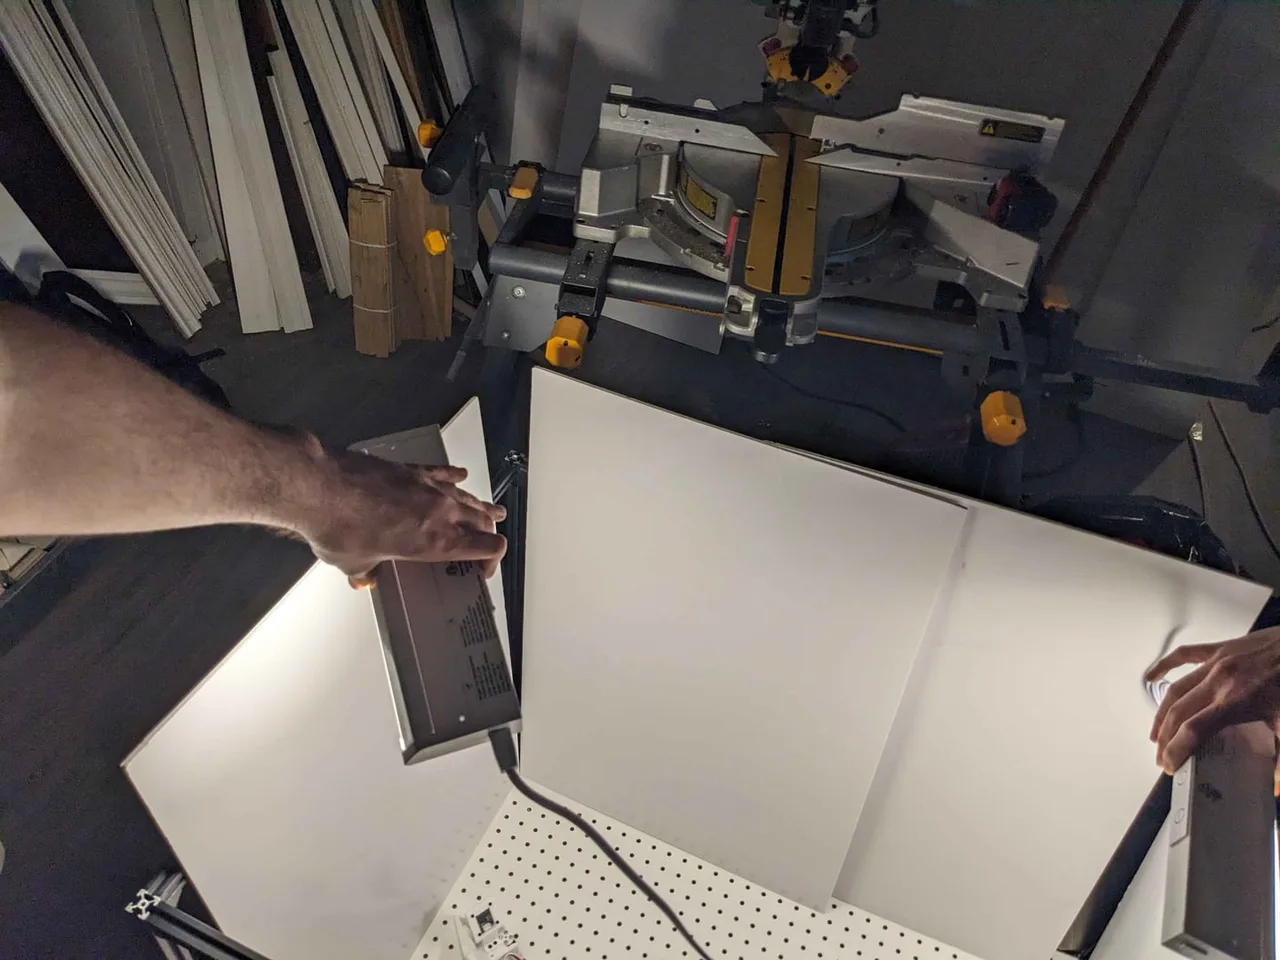
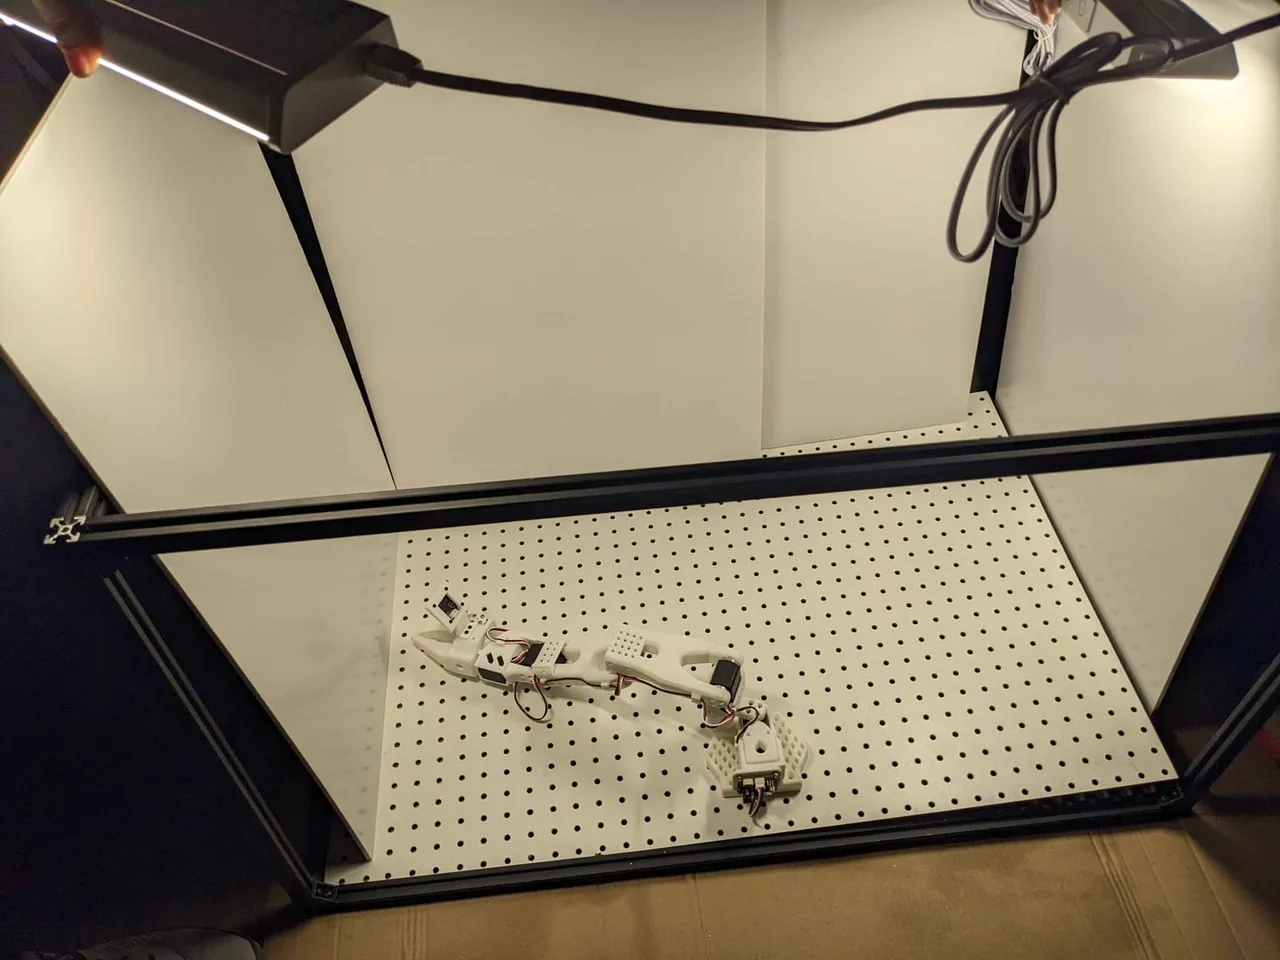
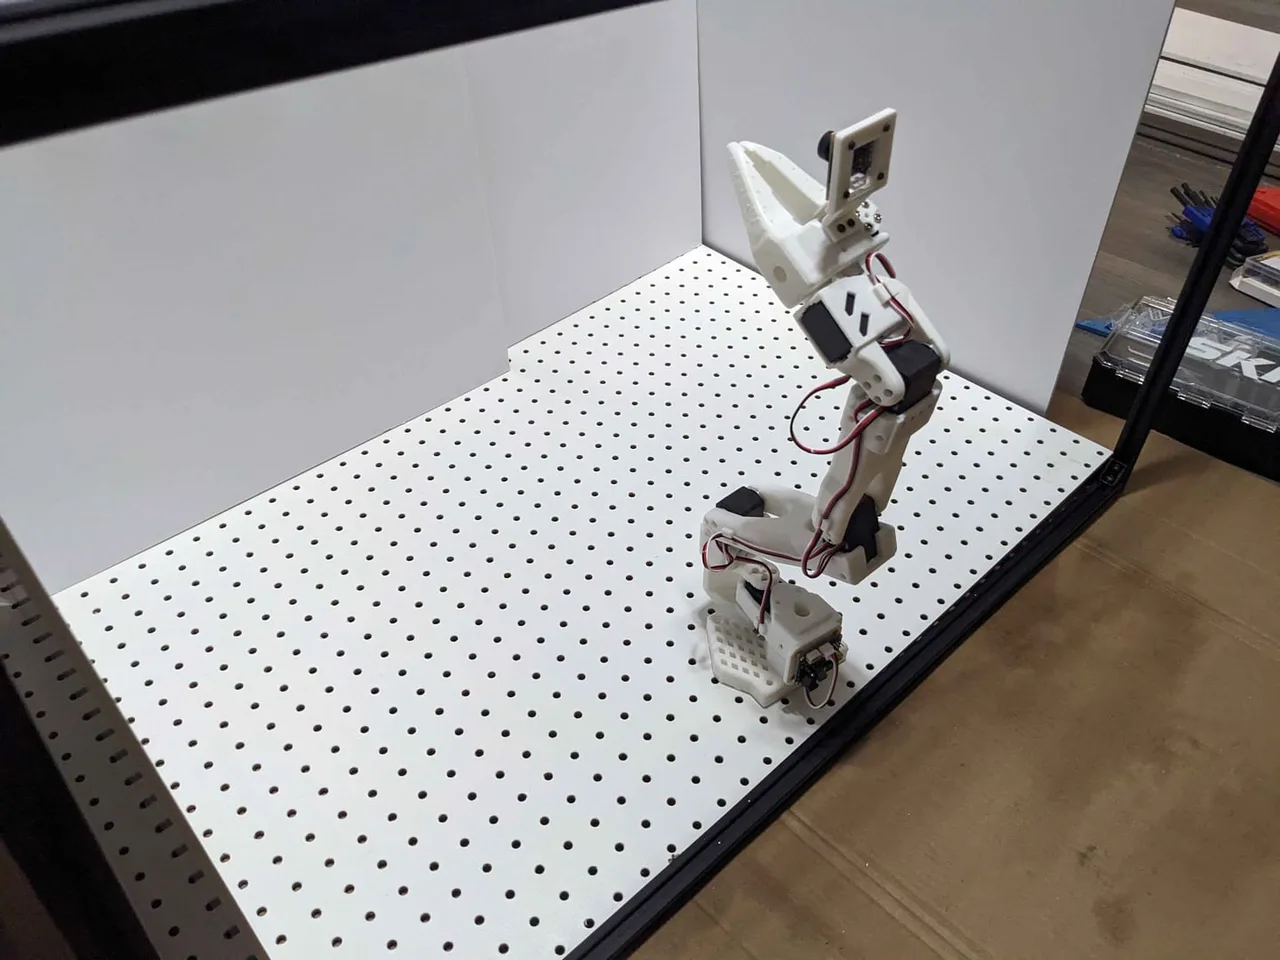
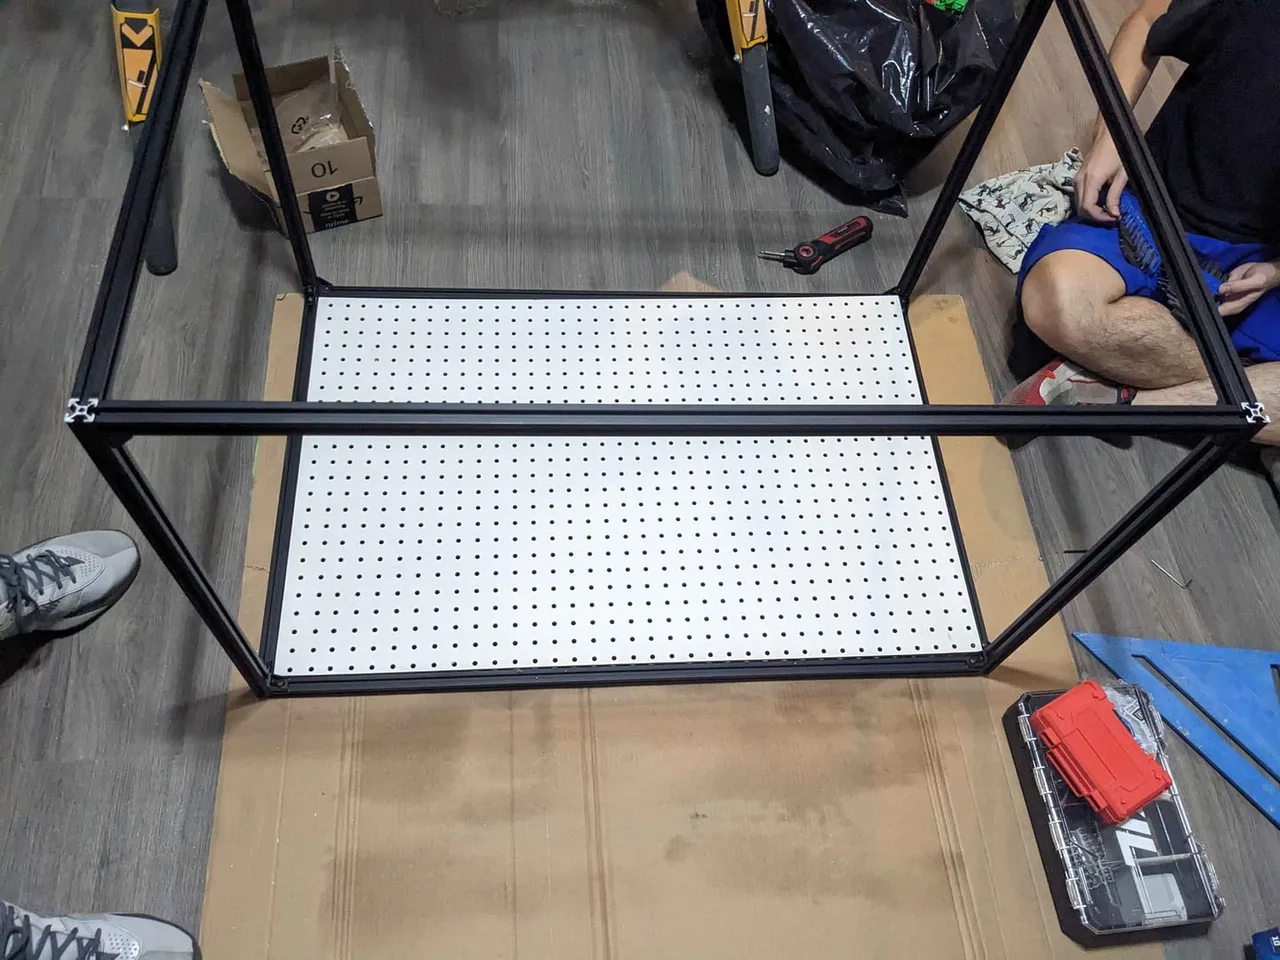
Our first policies broke when the green mat was missing or the window light changed, so we built a controlled enclosure for collecting data.
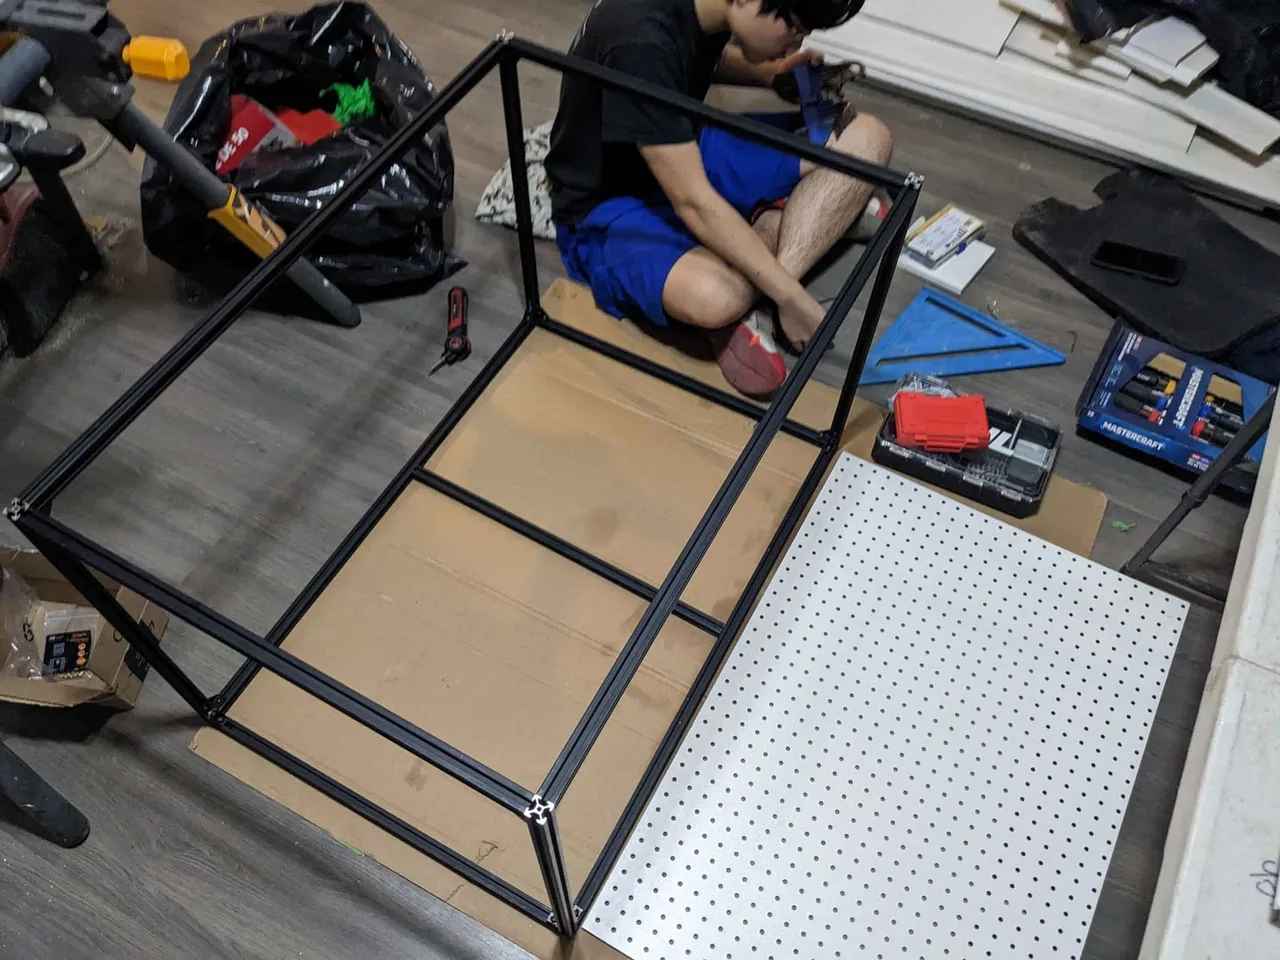
October 12.
The 2020 aluminium frame assembled on the floor beside the pegboardThe pegboard deck fitted into the bottom of the frameWhite foam board walls going up around the deckFitting an LED bar to the top of the frameThe enclosure lit from inside, with the follower arm on the deckThe follower arm standing on the pegboard deck inside the white enclosure