Ario Barin Ostovary

Software Engineering, University of Waterloo

2AK-Bot

Mars Rover built in a day. MasseyHacks Best Overall.

You know you did something right when they have to rewrite the rulebook because of you. ;)

We made a Mars Rover with a gripper and arm that moves around and cameras on it. Won Best Overall at MasseyHacks. It was the kind of project you'd normally spend a month on, but we got it done in a day. My first real all-nighter. No cheating though: we followed the rules, we just came way more prepared than anyone else. They actually changed the hackathon rules after that.
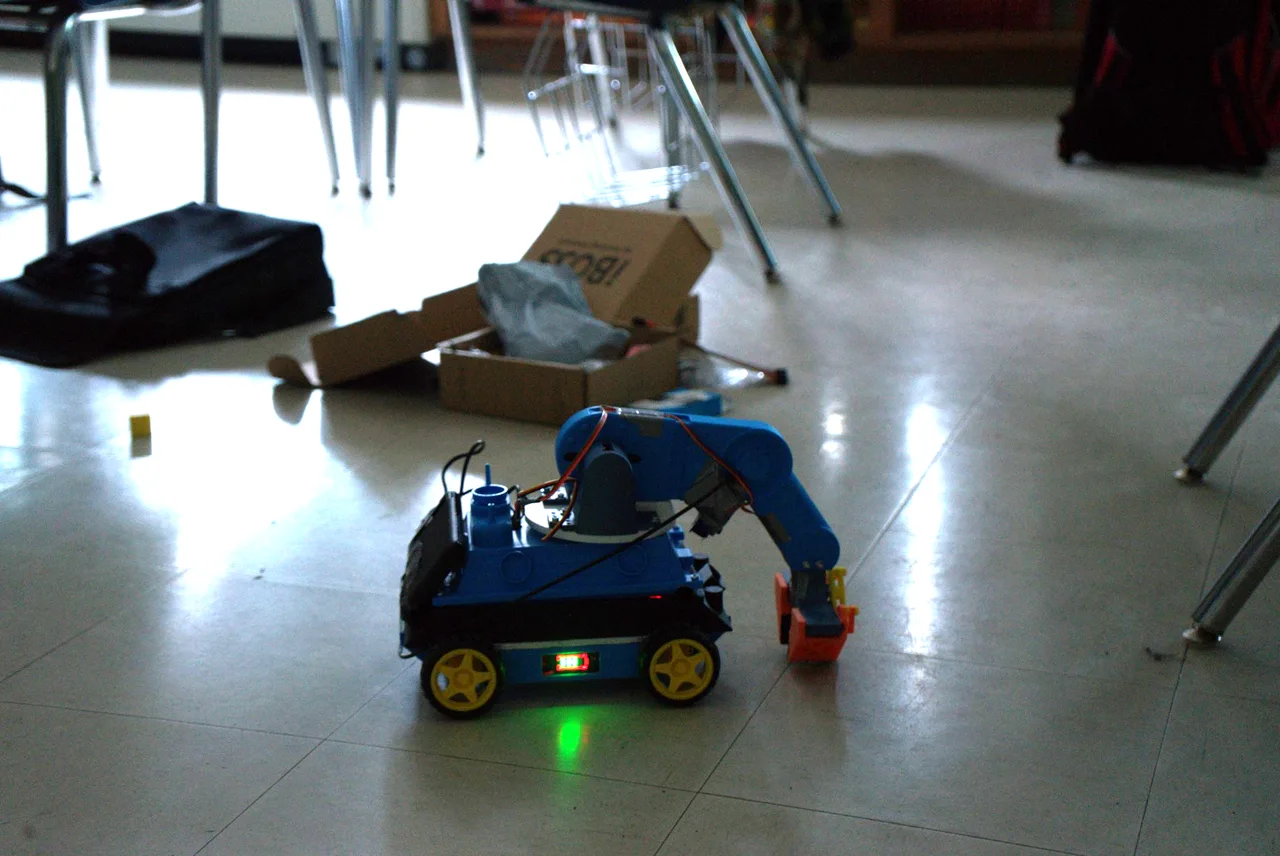
2AK-Bot Mars Rover

I made the Bluetooth communication between the controller, computer, and ESP32 to control the driving motors and servo motors. I also designed the gripper and arm and helped with the design of the base.
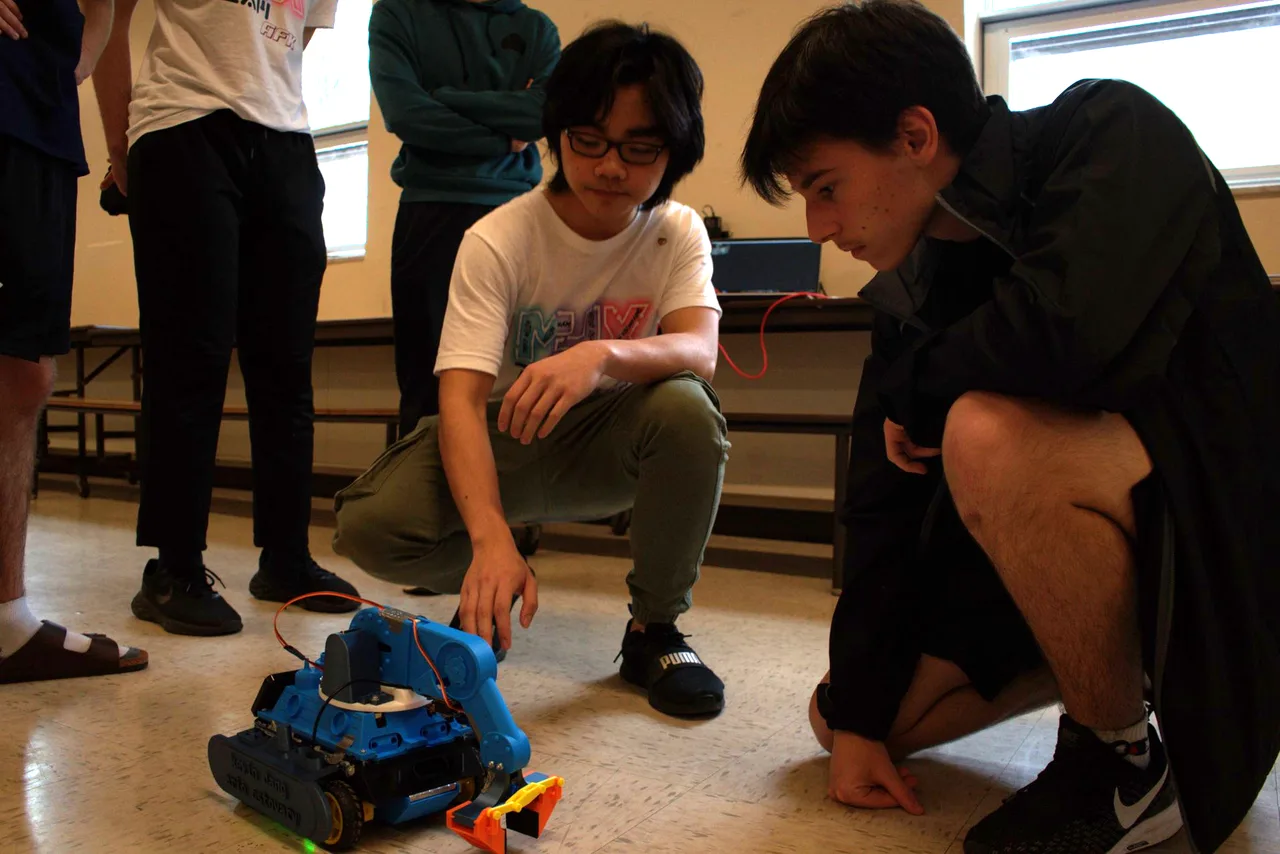
The rover's arm and gripper moving during a test.
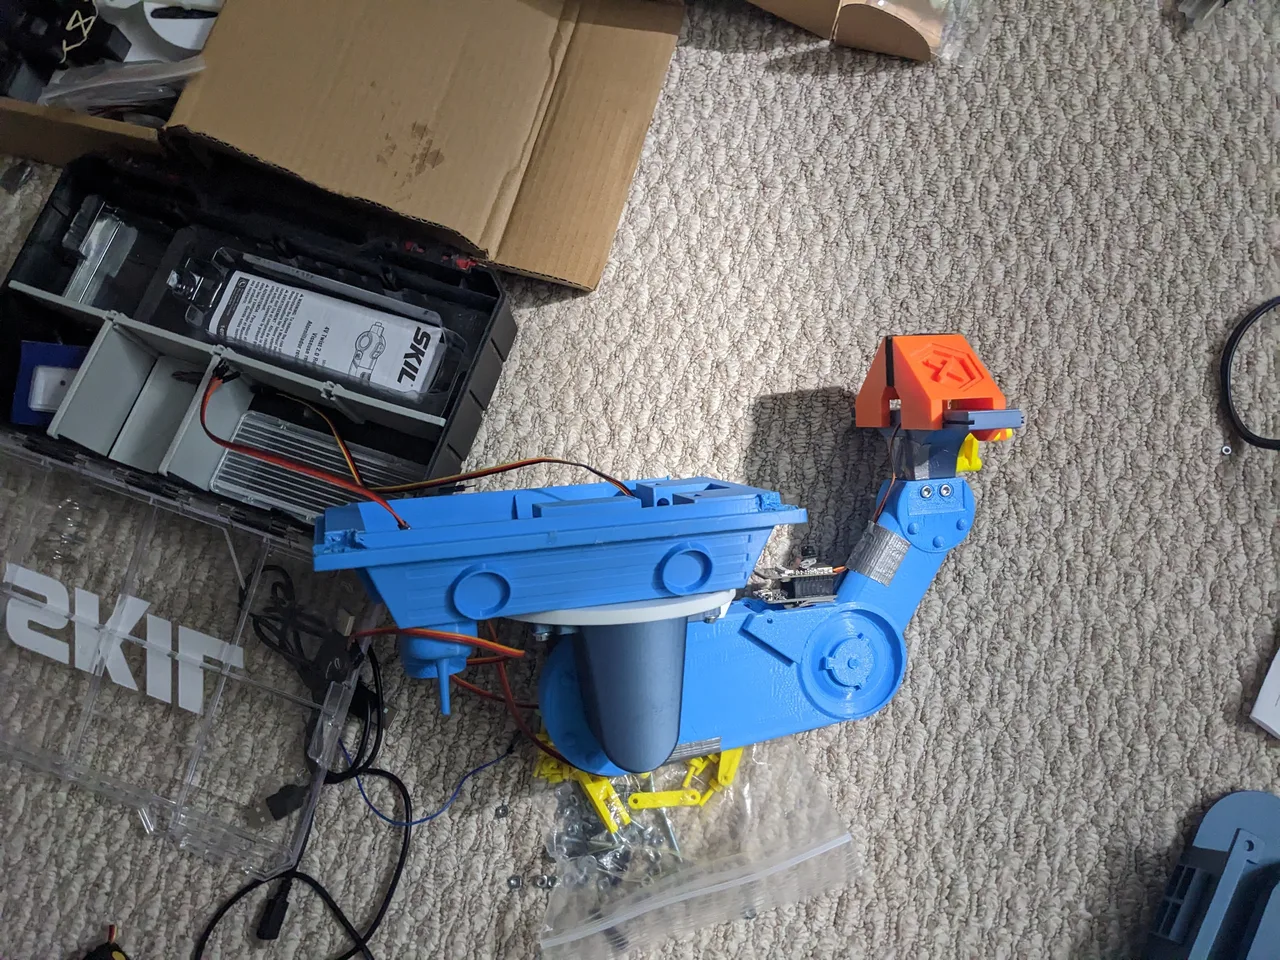
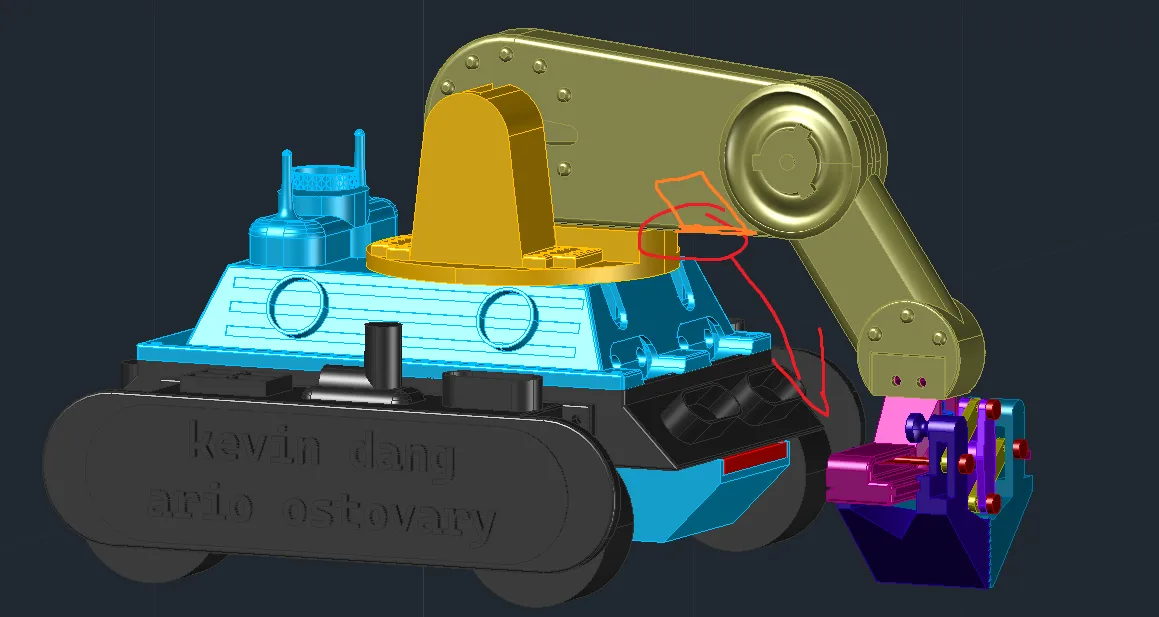
The rover assembly, including the arm and gripper.
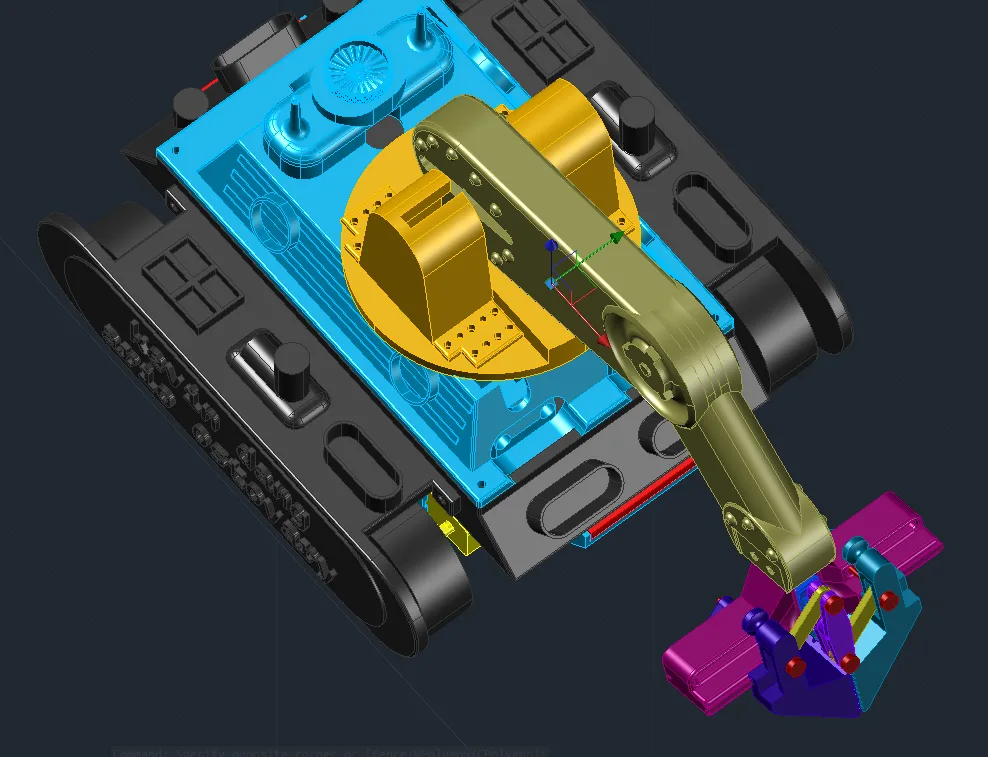
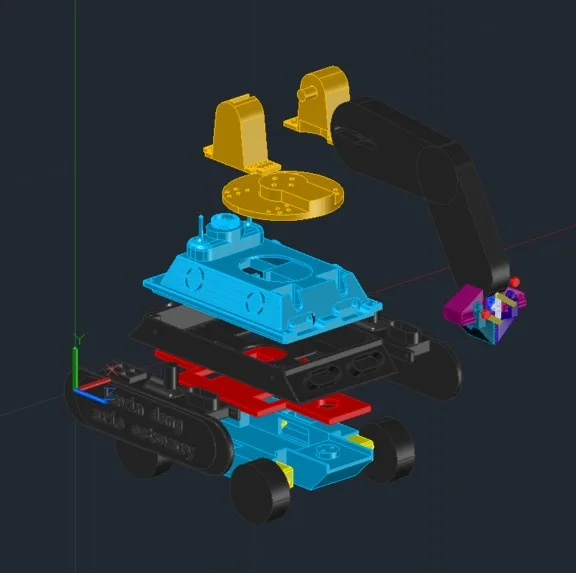
Exploded CAD view showing the rover base, body, rotating arm, and gripper

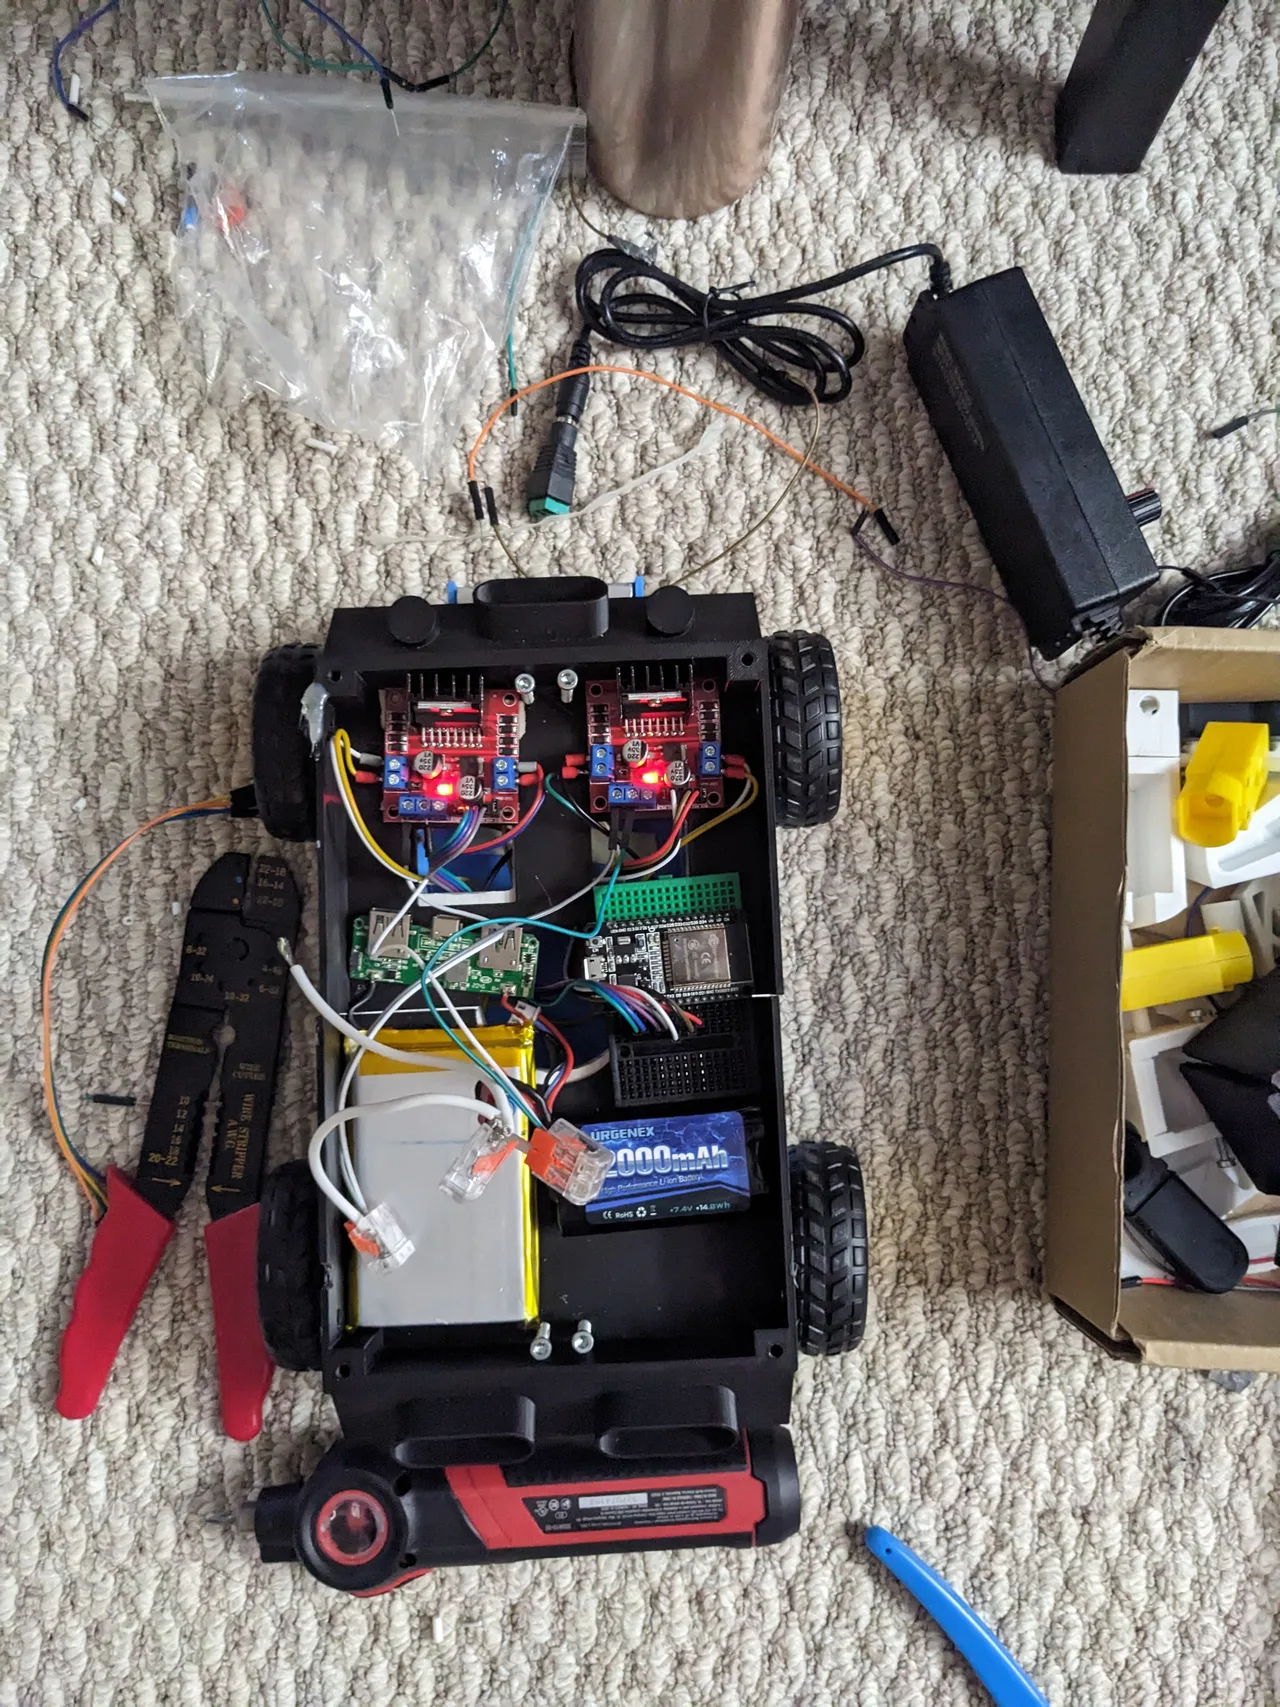
We had designed and printed the parts in advance and tested them individually. Putting them together was another matter. Components got fried, some printed parts needed holes melted into them with a soldering iron, and the battery bank ended up outside because there wasn't enough room inside.
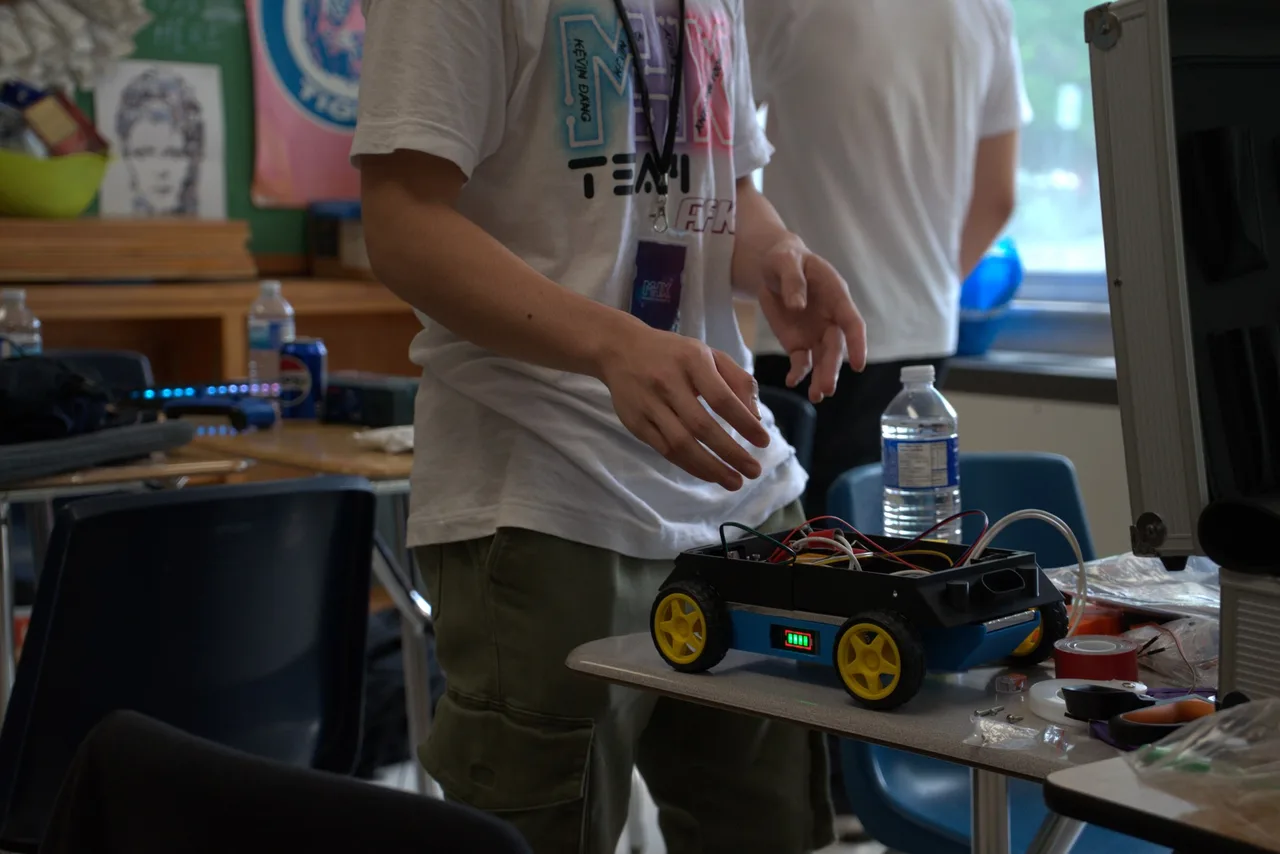
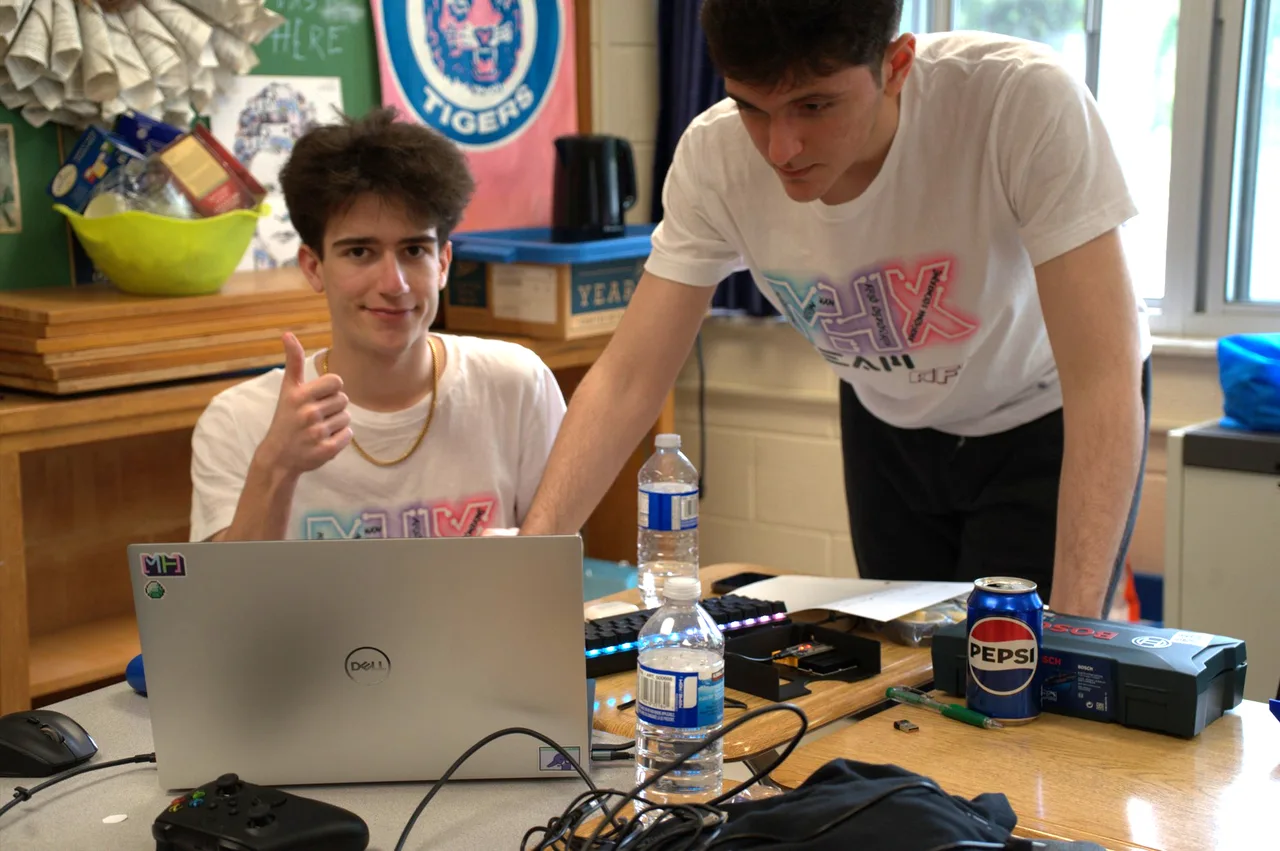
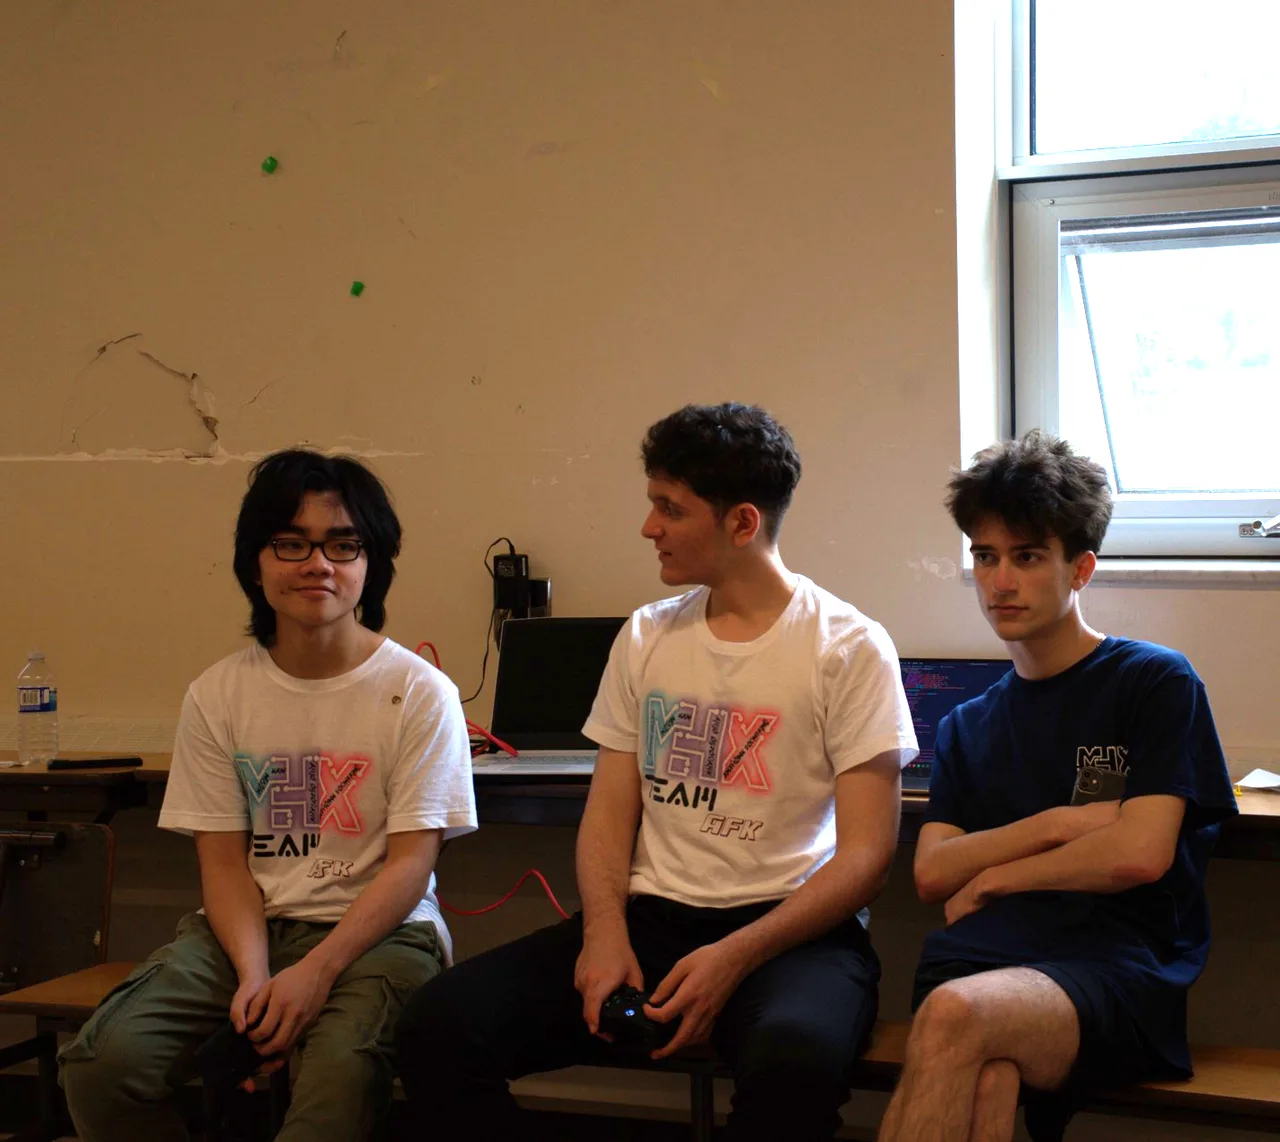
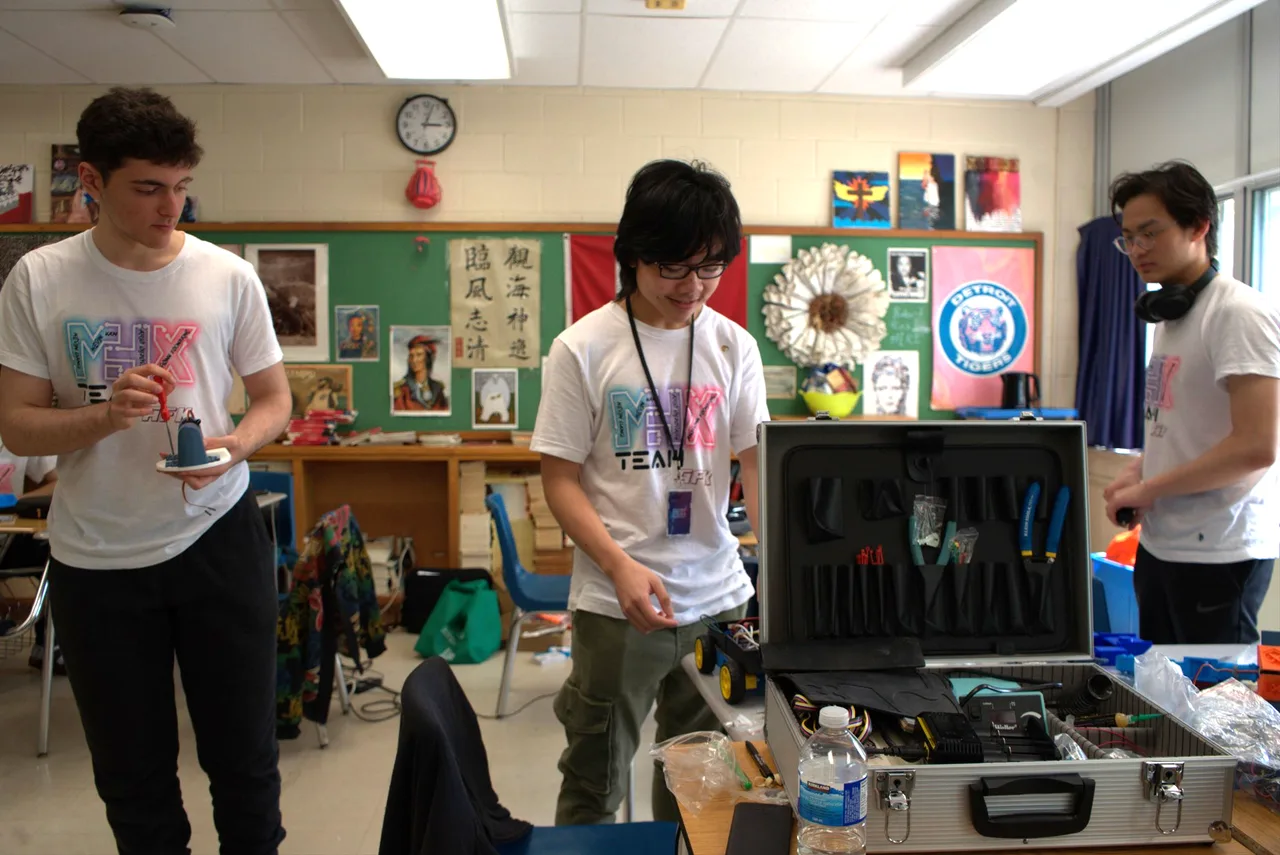
The open chassis on the workbench, and the team working beside it at MasseyHacks X.
The rover chassis open on the workbench, showing the wiring inside with the arm absentWorking on the bot
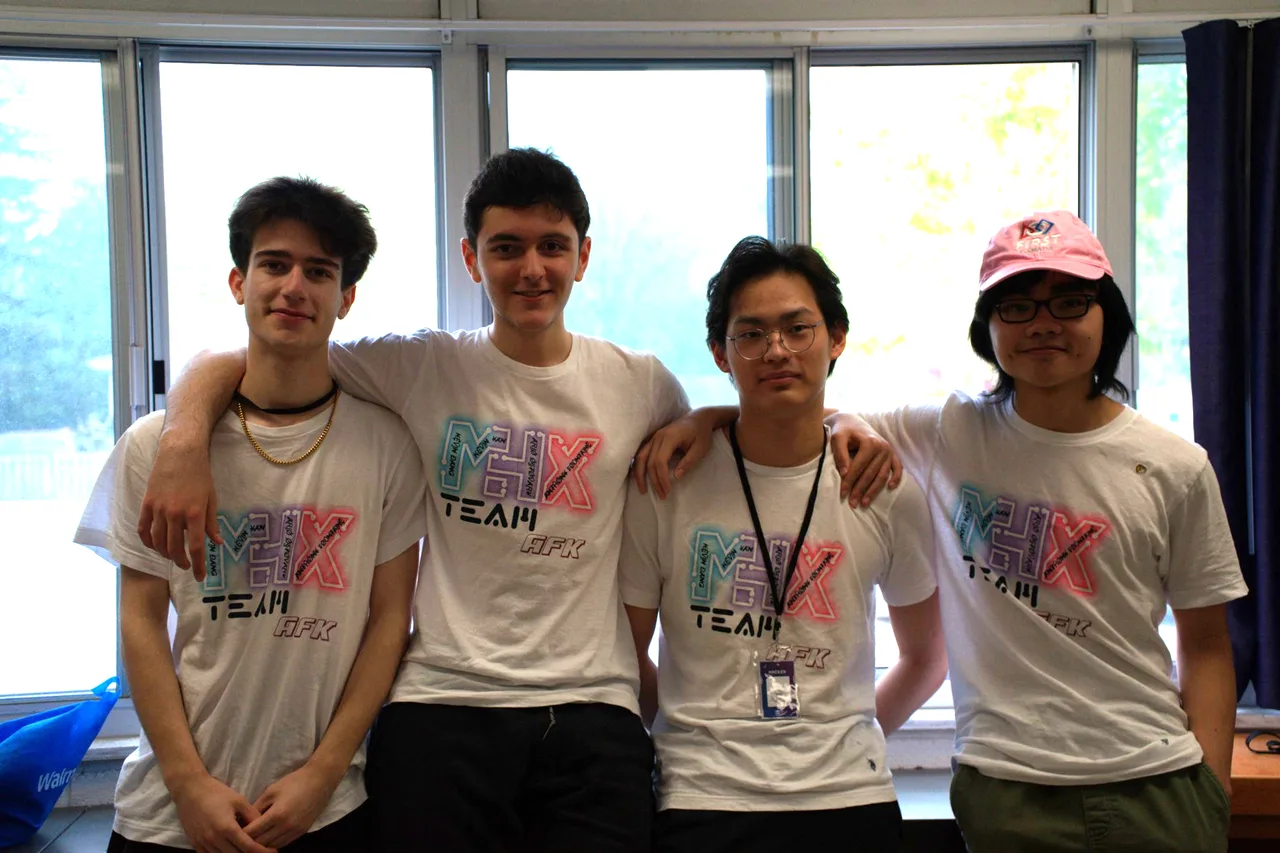
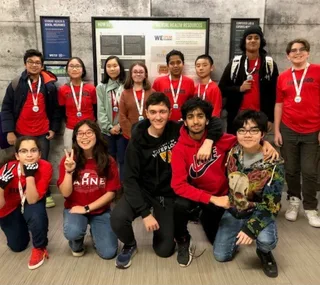
Team photoTeam photo 2Full team photoJudging session

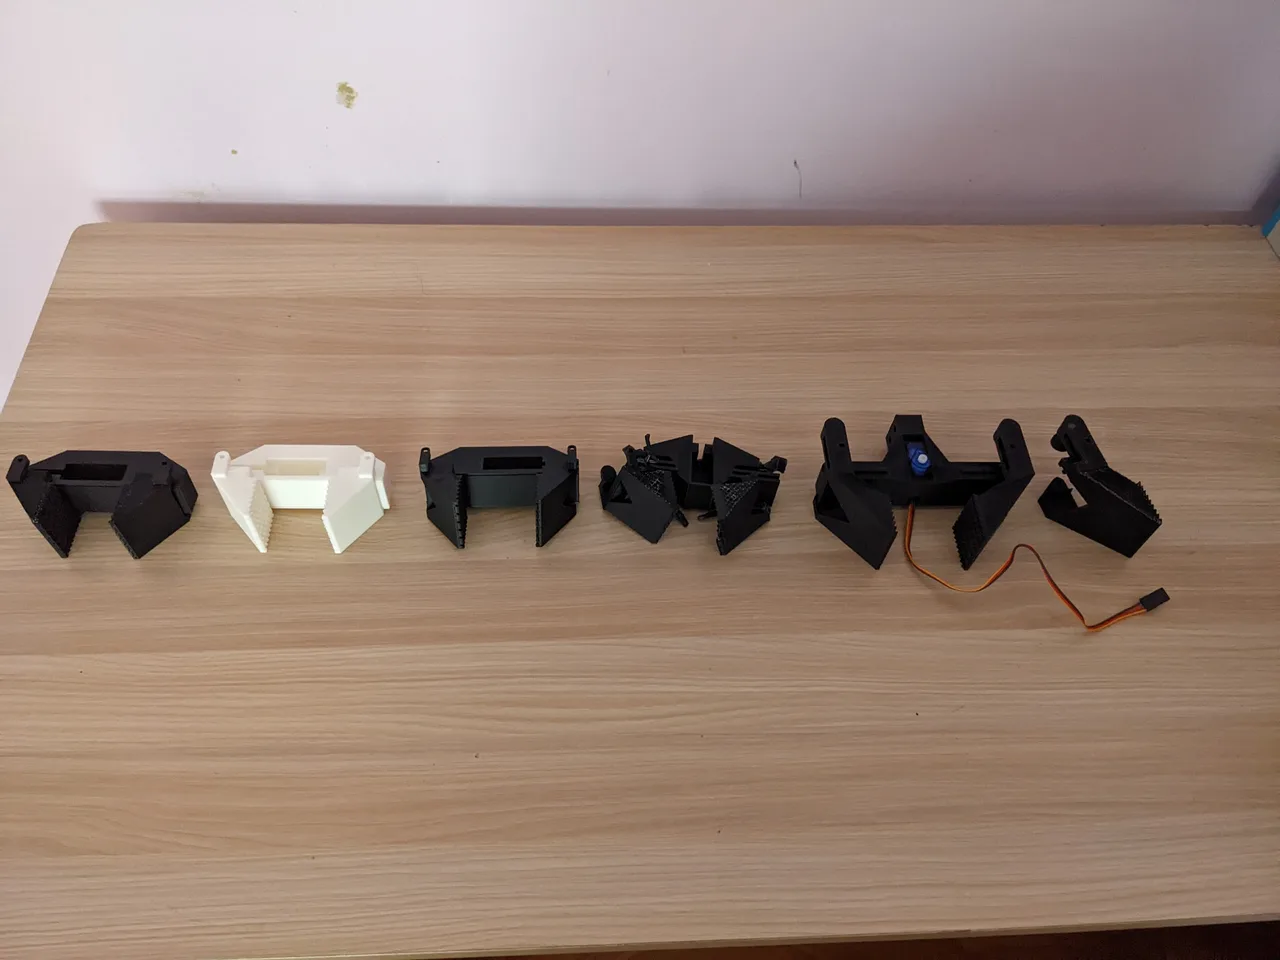
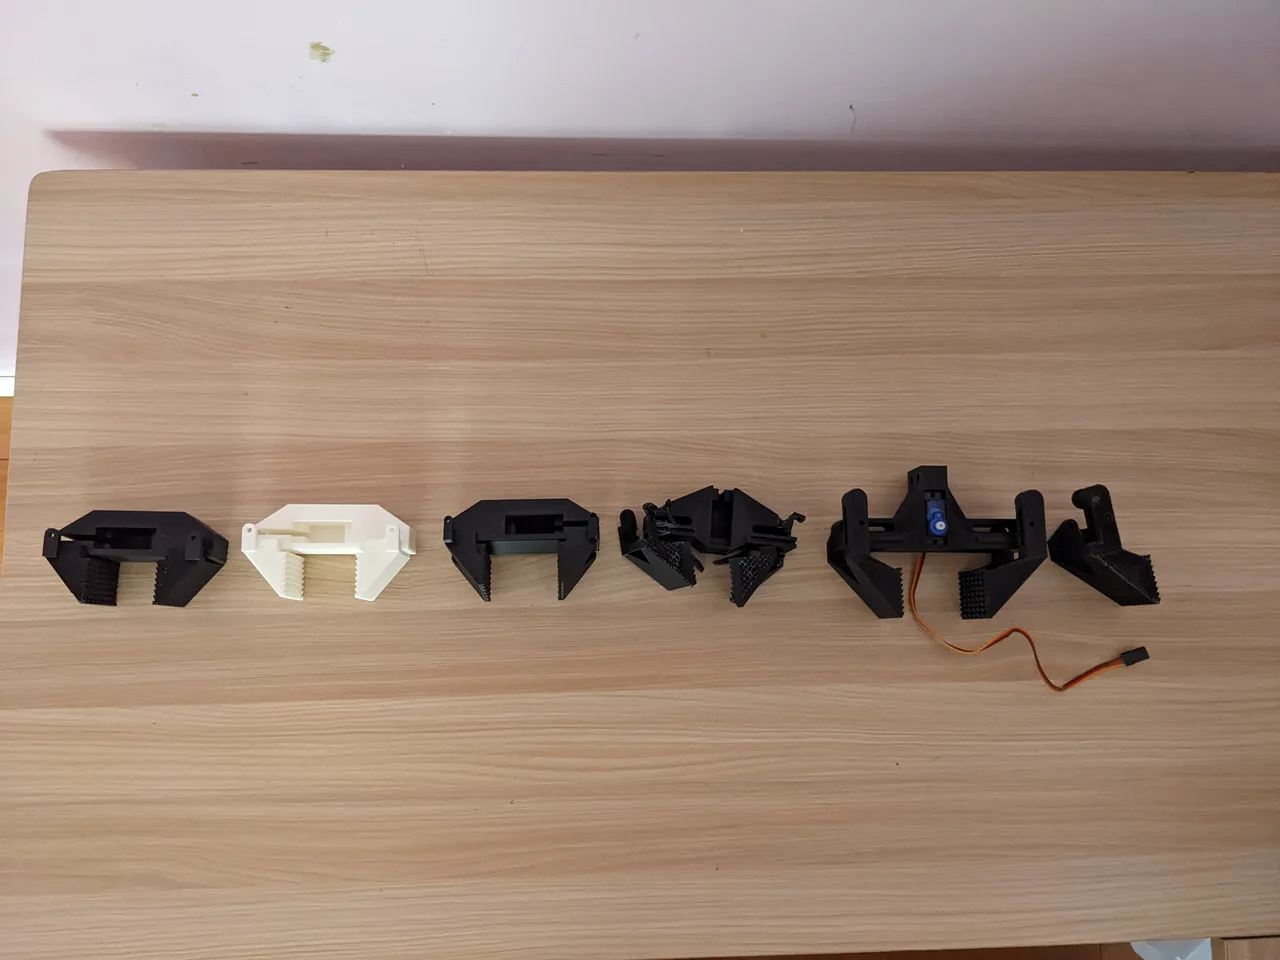
More gripper and arm iterations
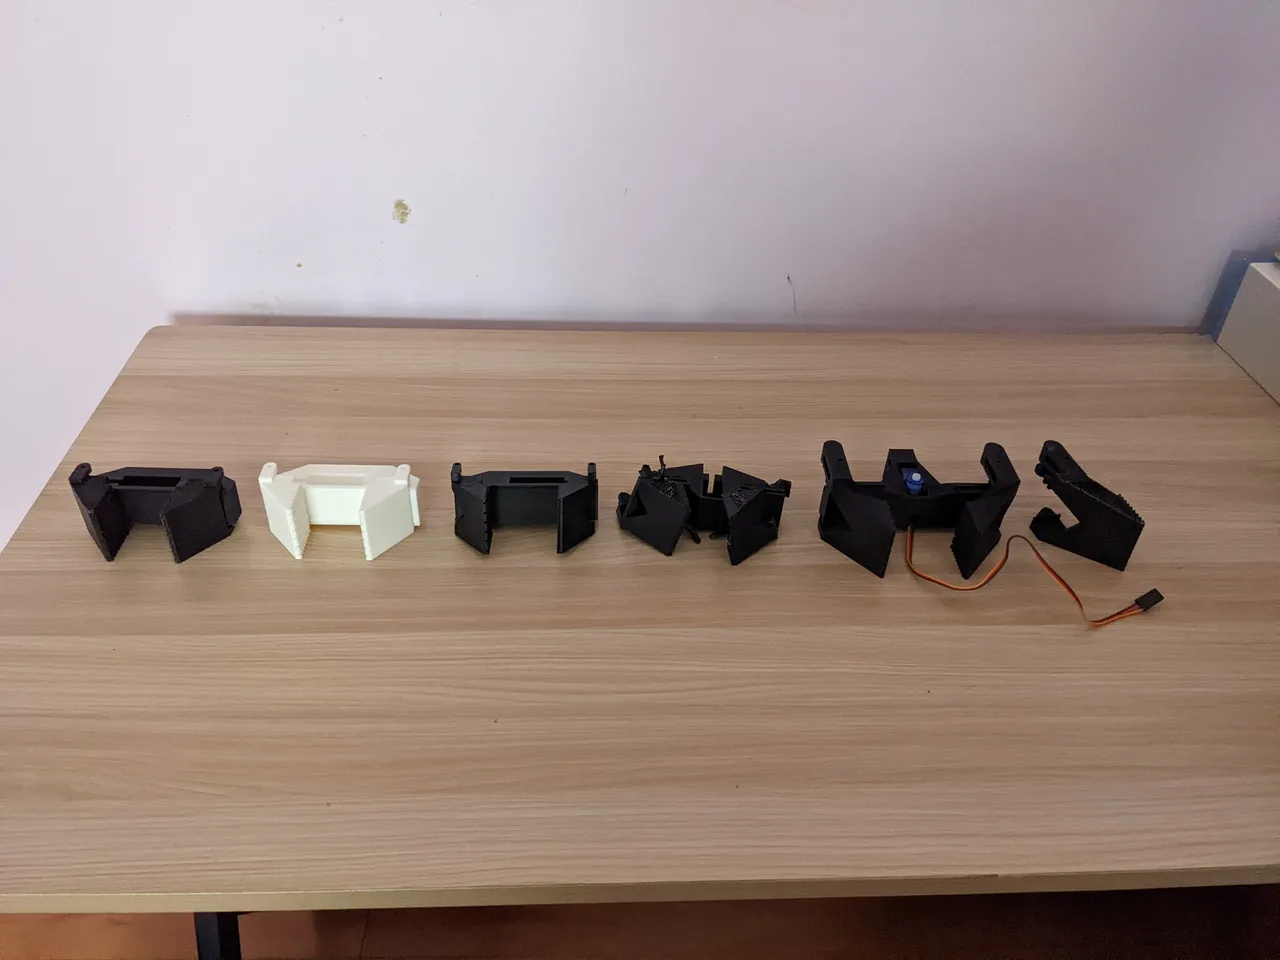
Six gripper revisions, including servo-equipped versions and a failed print.
Six printed gripper revisions lined up on a table, including servo-equipped versions and a damaged printAn alternate angle of the six printed gripper revisionsA closer view of the gripper lineup and servo wiring
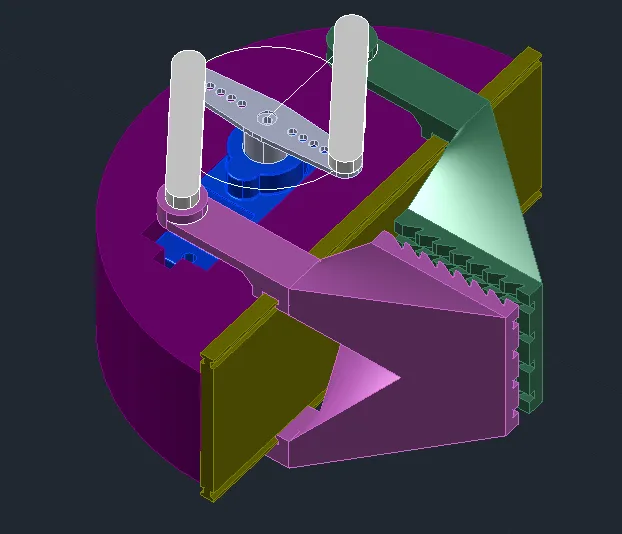
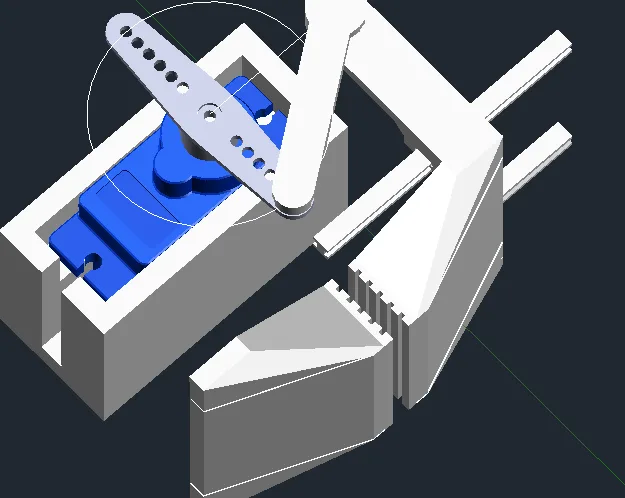
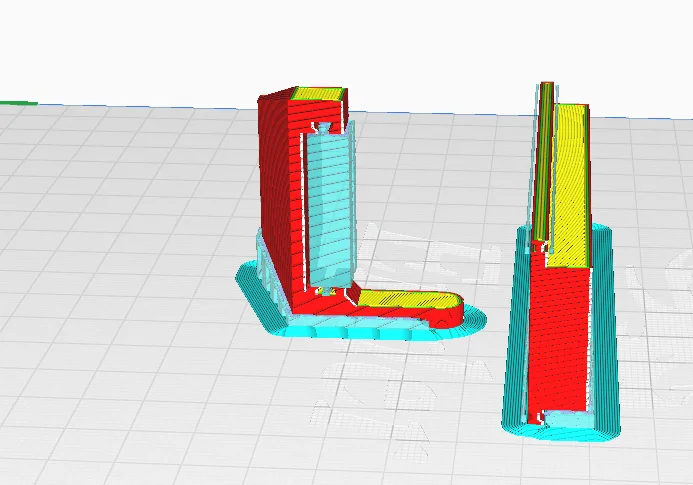
The gripper and linkage design, print-support preparation, and the arm in the rover assembly.
CAD model of the gripper with a servo linkage and toothed jawsClose-up CAD view of the servo horn and gripper linkageSlicer view of two gripper jaws with their print supportsCAD model of the rover with the gripper attached to its articulated arm
Testing a standalone printed gripper and servo linkage.
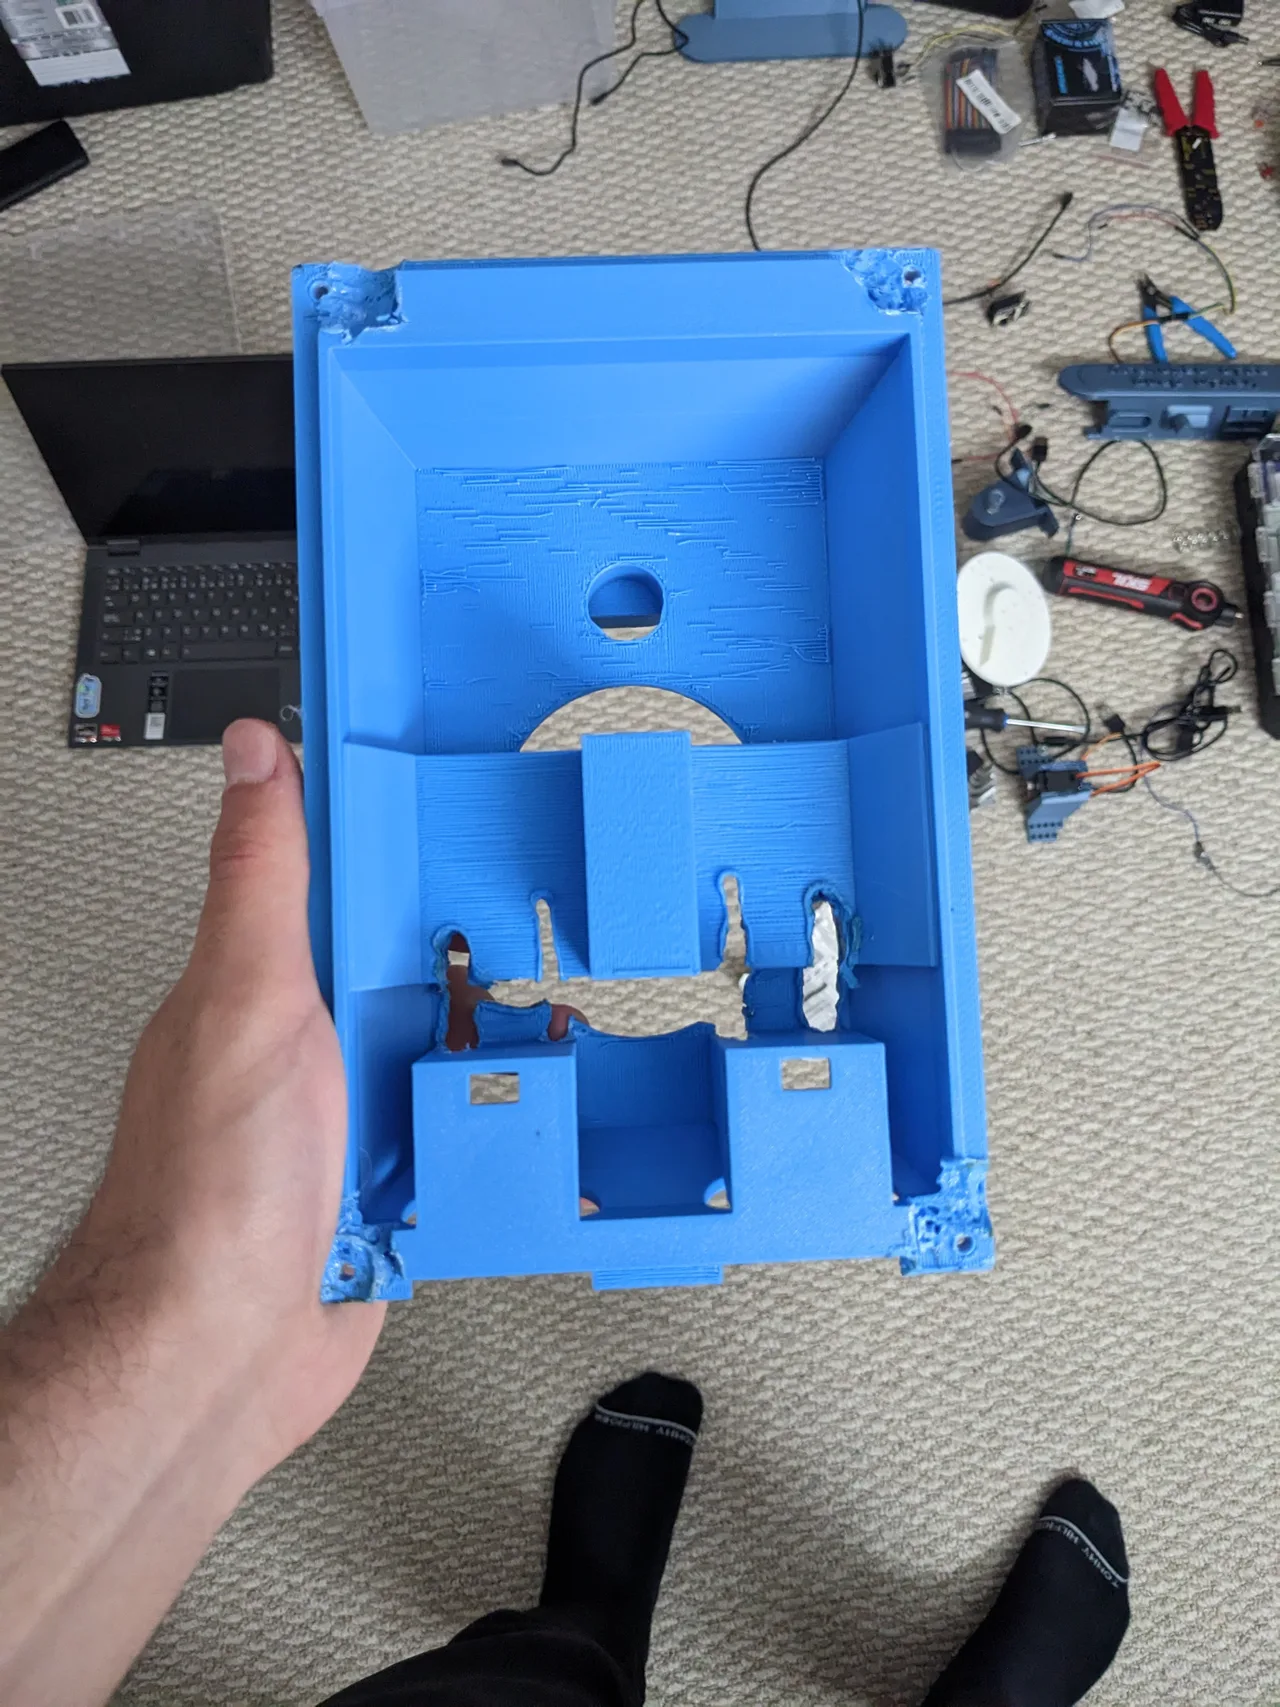
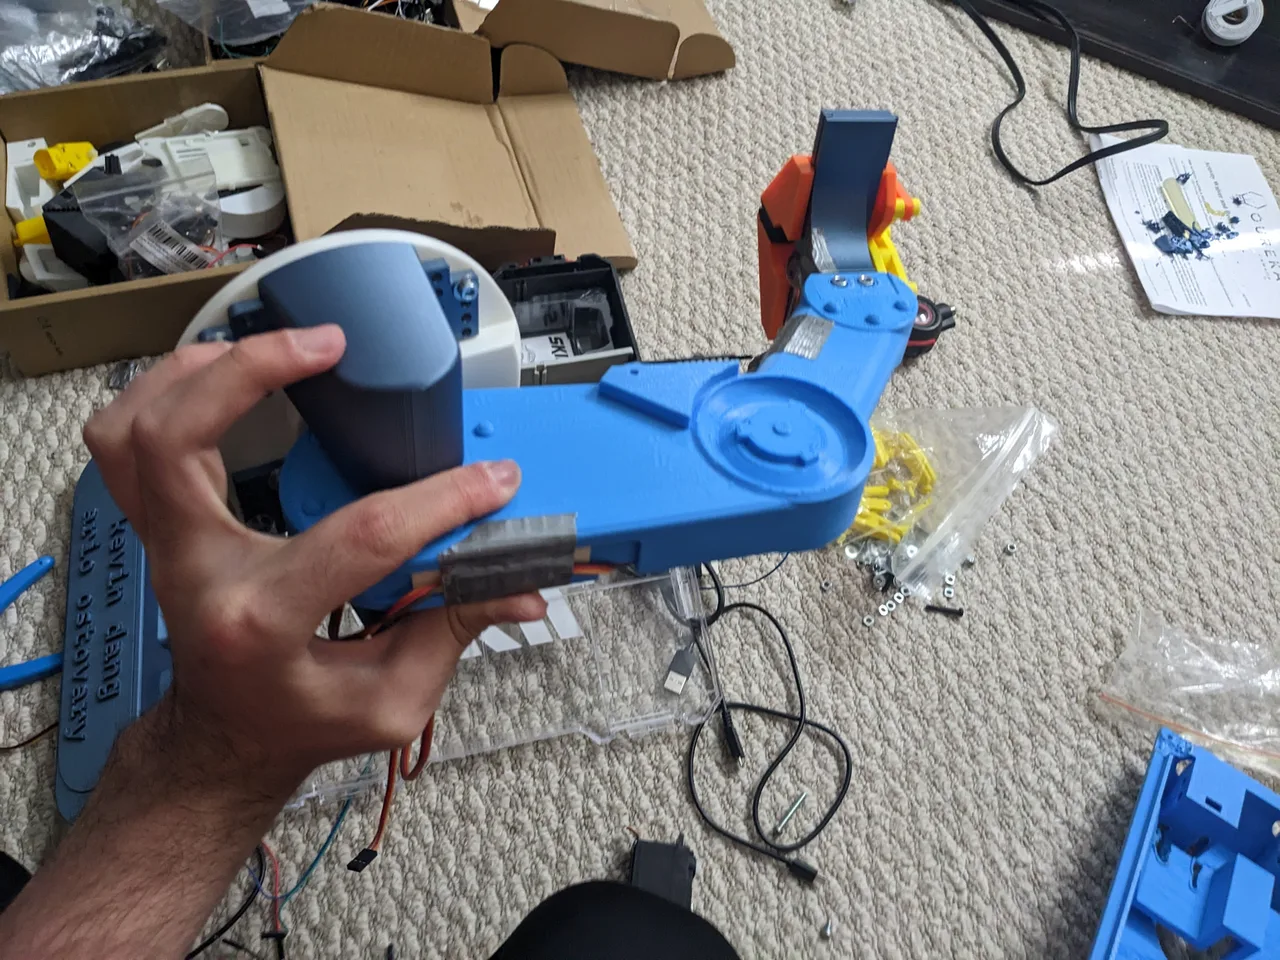
Further arm and base assembly photos from July 2024.
The blue printed base shell held open to show its internal mounting featuresThe blue articulated arm being held during assembly, with wires and gripper parts visibleThe printed arm, base and other parts laid out on the floor during assemblyThe rover base opened to show wiring, motor drivers and a battery
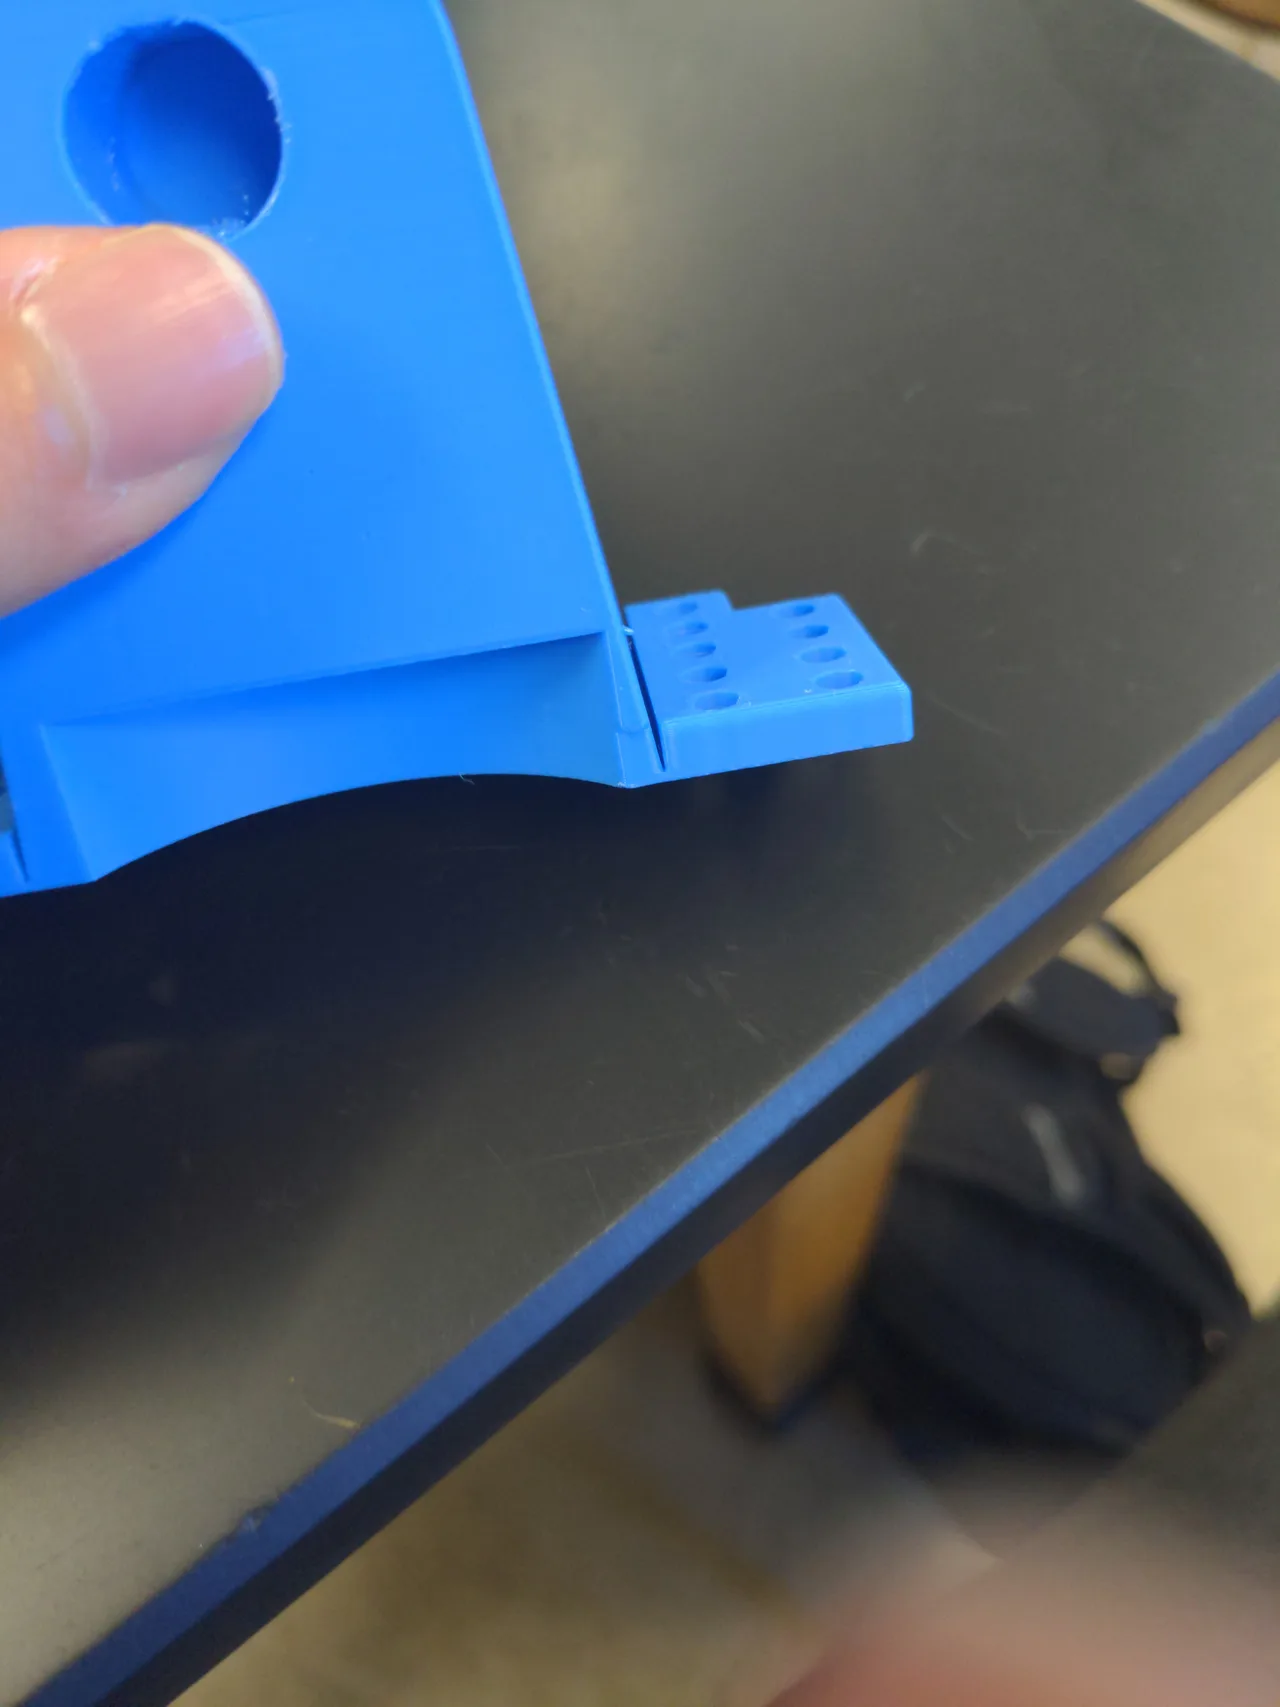
An oopsie: the bracket wasn't connected properly, leaving a break line through the print.
A blue printed housing with a visible separation line where its mounting bracket meets the body
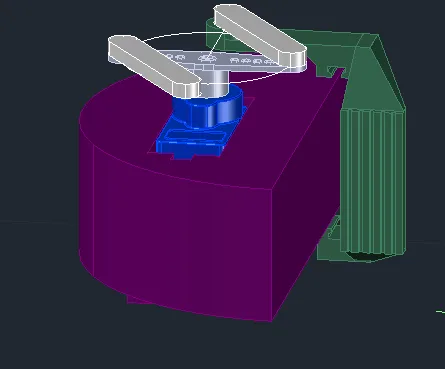
Another gripper design and a side view of the rover assembly.
A block-shaped gripper design with a servo and linkage above itSide view of the 2AK-Bot CAD assembly with tracks, arm and gripper